Join
Building generative models for motion synthesis or control Experimenting with humanoids, robot arms, exoskeletons and dexterous hands Training virtual agents using RL and transfer to real robots Collecting data with different motion capture systems Pre-training or fine-tuning VLMs for policy dev
Before you start
- Basic Python familiarity
- Comfort with algebra or calculus basics
- Interest in robotics systems
About this guide
Building generative models for motion synthesis or control Experimenting with humanoids, robot arms, exoskeletons and dexterous hands Training virtual agents using RL and transfer to real robots Collecting data with different motion capture systems Pre-training or fine-tuning VLMs for policy development Developing and using multibody simulators Designing and building 3D-printable humanoids Solving both convex and non-convex optimization problems [...] #### Humanoid Robotic Foundation Mode
Common questions
What will I learn in Join?
Building generative models for motion synthesis or control Experimenting with humanoids, robot arms, exoskeletons and dexterous hands Training virtual agents using RL and transfer to real robots Collecting data with different motion capture systems Pre-training or fine-tuning VLM
Is Join free?
HumanoidHub has not verified public pricing for this guide. Open Stanford Online for the current access terms before enrolling.
Do I need any prerequisites?
Recommended prep: Basic Python familiarity; Comfort with algebra or calculus basics; Interest in robotics systems.
How long does it take?
1 hours total. Most learners complete this guide in self-directed sessions over a few weeks.
Does it offer a certificate?
This guide does not include a formal certificate. Focus is on the learning material itself.
Related guides
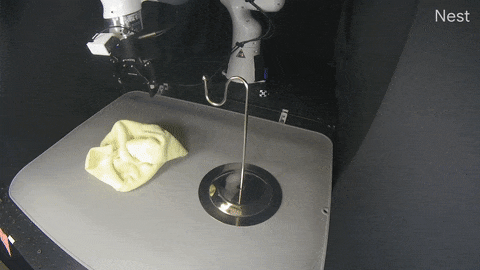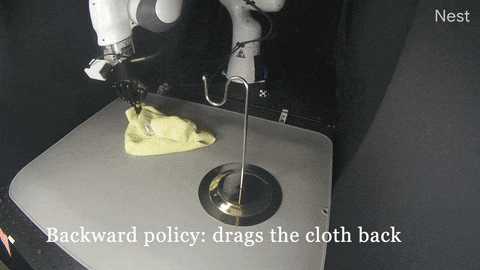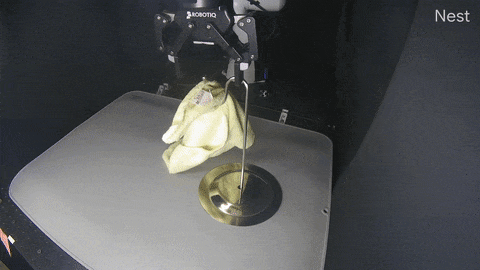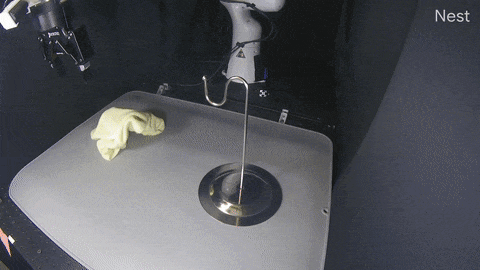
Self-Improving Robots: Embracing Autonomy in Robot Learning
The official Stanford AI Lab blog

Stanford HAI Conference Explores Robotics in a Human-Centered World: Hype, Hope, and Future Directions | Stanford HAI
Scholars zeroed in on the need for data, generalization, and better human experience.
A faster way to teach a robot
A new technique enables a human to efficiently fine-tune a robot that failed to complete a desired task with very little effort on the part of the human. Their system uses algorithms, counterfactual explanations, and feedback from the user to generate synthetic data it uses to quickly fine-tune the
Teaching Humanoid Robots Real-World Skills at MIT CSAIL’s Living Lab
Member Resources MIT In This Section Home MIT In This Section Filter Options In This Section Filter Options In This Section # Teaching Humanoid Robots Real-World Skills at MIT CSAIL’s Living Lab At MIT CSAIL's Living Lab, humanoid robots are learning to adapt, manipulate, and solve real p
Unit 8. Robotics | Brains, Minds and Machines Summer Course | Brain and Cognitive Sciences
This page summarizes the unit topic and activities, and links to lecture videos, notes and further study resources.

[PDF] 1st Reading - Personal Robots Group
5.6. Learning results The tutoring of tasks exemplifies our approach to teaching as a collaborative interac-tion. Joint attention is established both on the object level and on the task structure level. The robot uses subtle expression to indicate to the human tutor when it is ready to learn somethin
Robots that use these skills
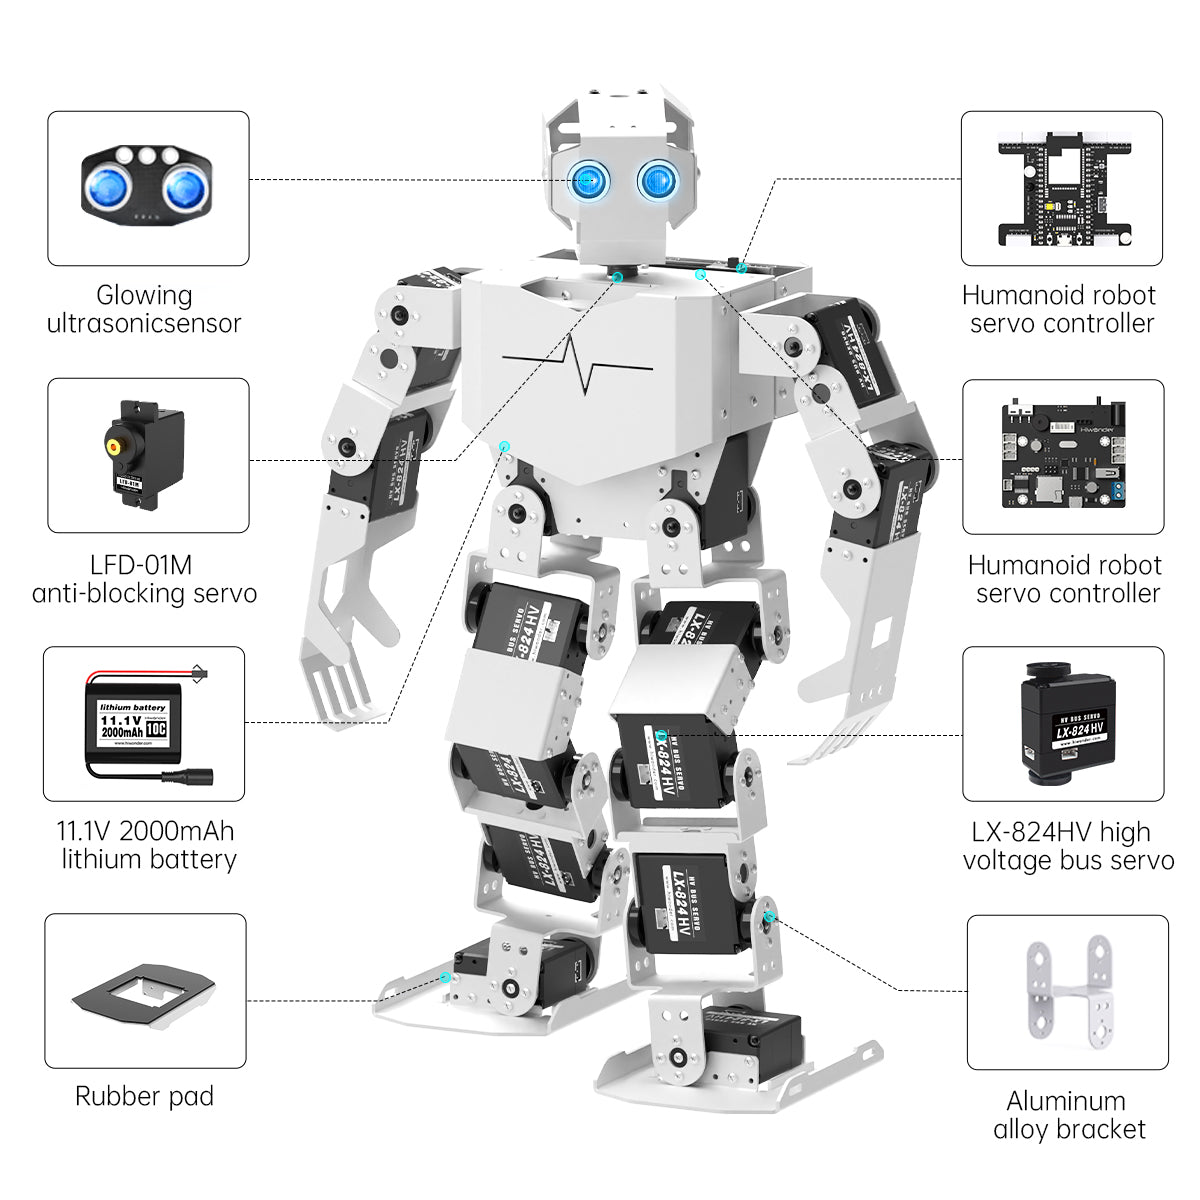
HiWonder TonyBot Humanoid Robot Kit
Hiwonder
Hiwonder TonyBot is a small humanoid (biped) robot kit for STEM learning with 16 DOF servo joints and app/program control.
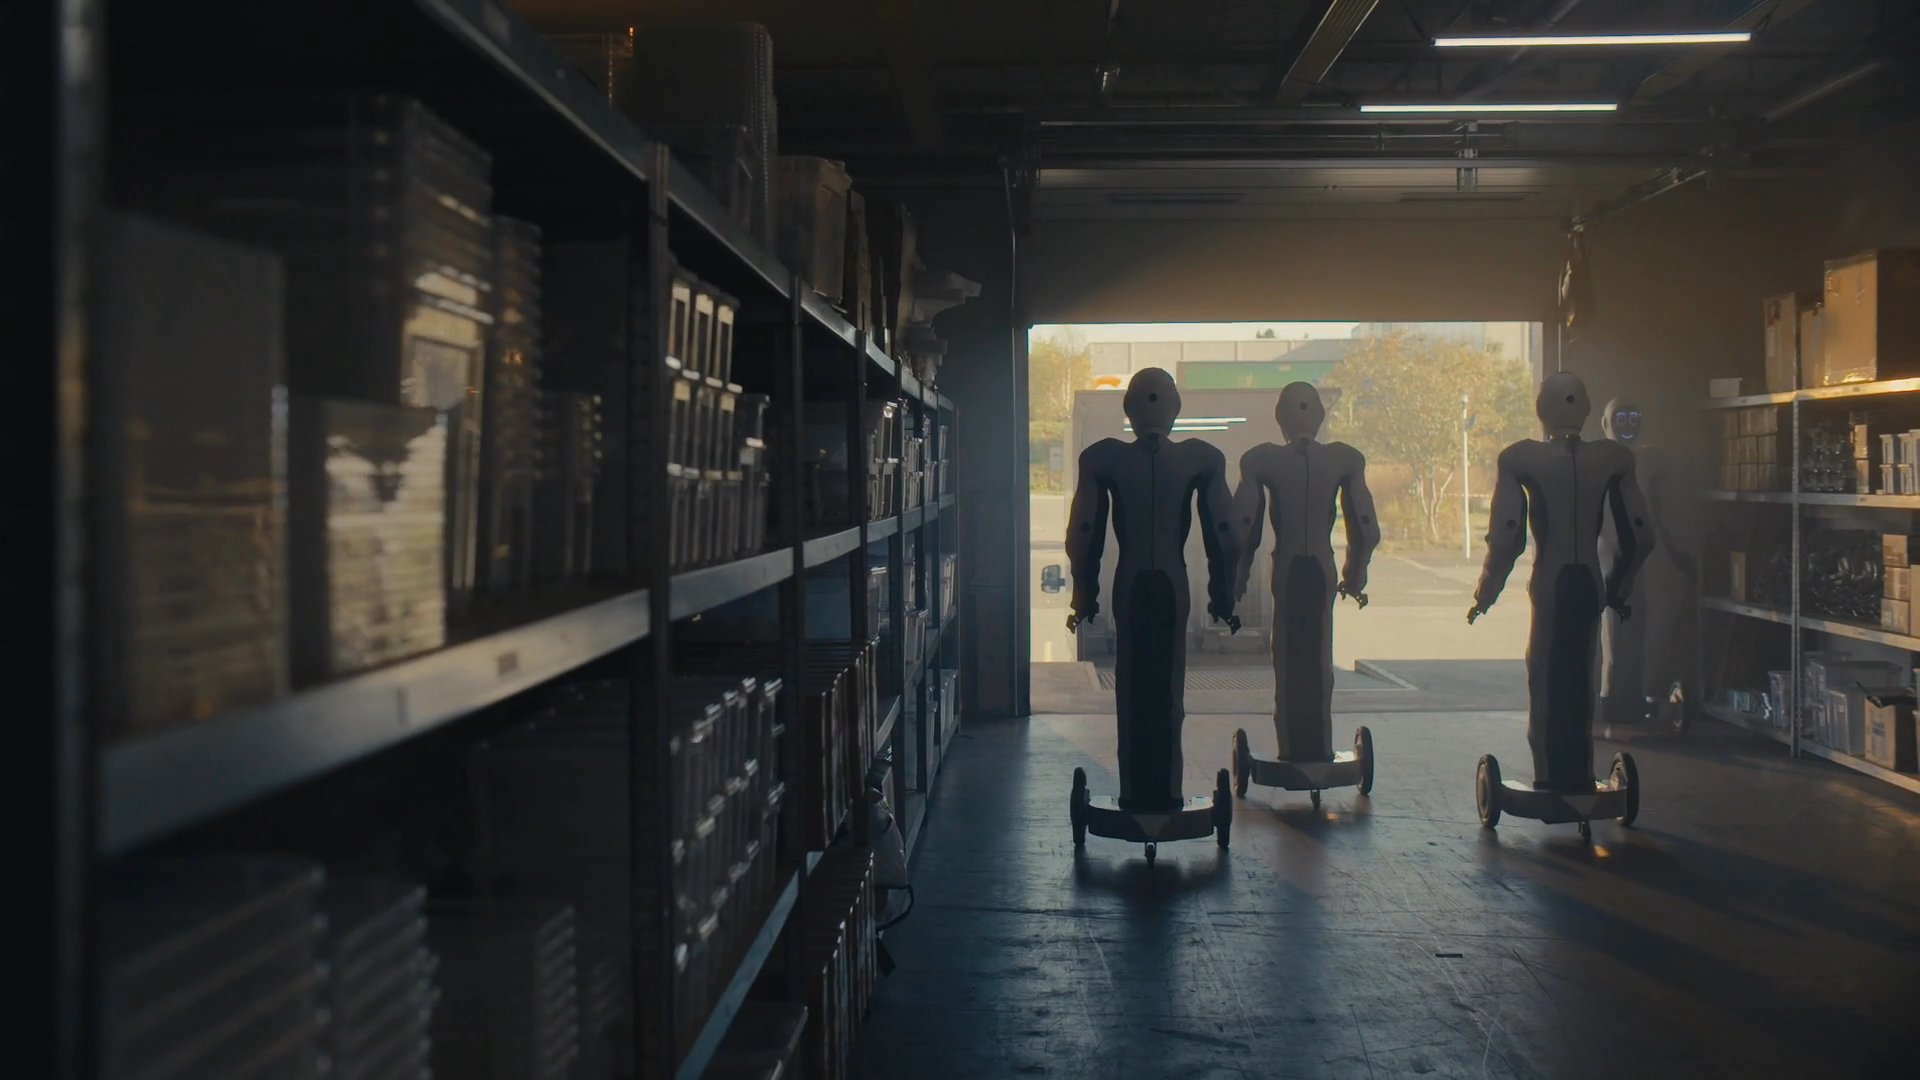
1X EVE
1X Technologies
1X EVE is a wheeled humanoid robot from 1X Technologies aimed at mobile service work in institutional and industrial settings.
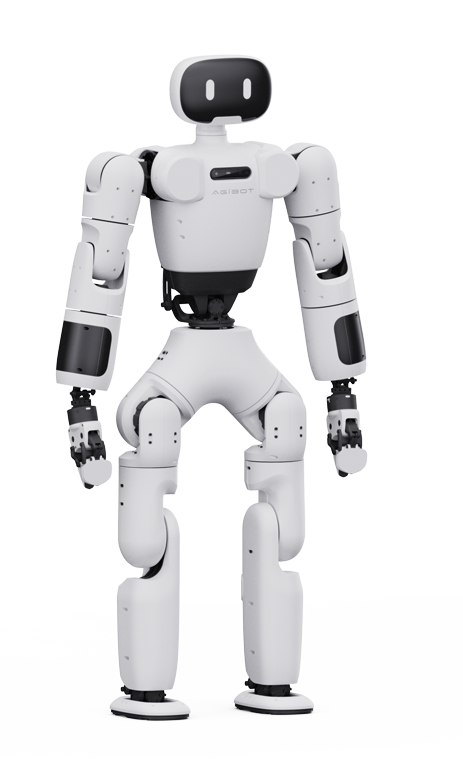
AgiBot X1
AgiBot
AgiBot X1 is a 130 cm, 33 kg open-source humanoid platform with 34 DOF for research and education.
Refer a learner and get early access to our paid pathways and 1:1 mentorship pilot.
Join referral listNew robots, industry moves, and funding in your weekly robotics briefing.
Unsubscribe anytime.