2.12: Introduction to Robotics | MIT Department of Mechanical Engineering
“This course is an introduction,” says instructor Professor Harry Asada. “We don’t assume anything about the students’ backgrounds. We just assume we share one thing in common: a love of complex motion. Motion is important in any area of mechanical engineering, but it’s particularly important in rob

Before you start
- Basic Python familiarity
- Comfort with algebra or calculus basics
- Interest in robotics systems
About this guide
“This course is an introduction,” says instructor Professor Harry Asada. “We don’t assume anything about the students’ backgrounds. We just assume we share one thing in common: a love of complex motion. Motion is important in any area of mechanical engineering, but it’s particularly important in robotics – we wouldn’t have robotics without it.”
An elective class for upperclassman, 2.12 goes beyond abstracts, providing students with a way to visualize complex mathematical concepts and a chance t
Common questions
What will I learn in 2.12: Introduction to Robotics | MIT Department of Mechanical Engineering?
“This course is an introduction,” says instructor Professor Harry Asada. “We don’t assume anything about the students’ backgrounds. We just assume we share one thing in common: a love of complex motion. Motion is important in any area of mechanical engineering, but it’s particula
Is 2.12: Introduction to Robotics | MIT Department of Mechanical Engineering free?
HumanoidHub has not verified public pricing for this guide. Open MIT OpenCourseWare for the current access terms before enrolling.
Do I need any prerequisites?
Recommended prep: Basic Python familiarity; Comfort with algebra or calculus basics; Interest in robotics systems.
How long does it take?
Self-paced (provider defined). Most learners complete this guide in self-directed sessions over a few weeks.
Does it offer a certificate?
This guide does not include a formal certificate. Focus is on the learning material itself.
Related guides
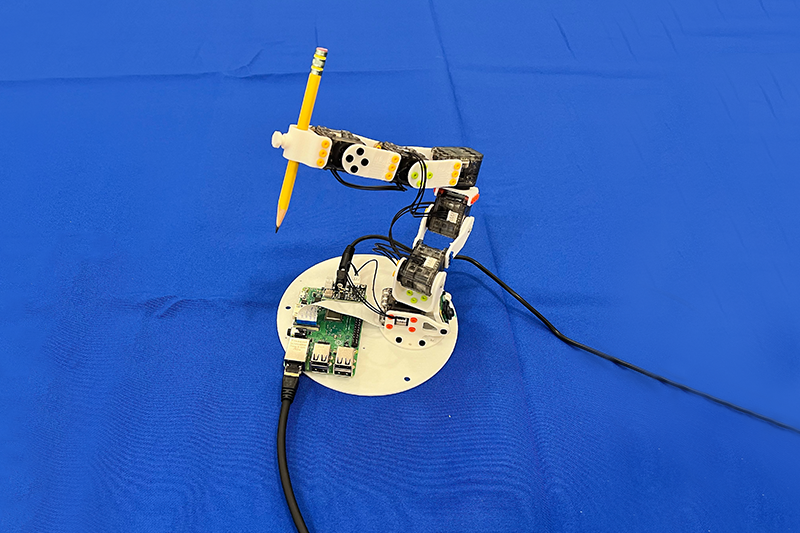
Robot, know thyself: New vision-based system teaches machines to understand their bodies
A vision-based control system called Neural Jacobian Fields enables soft and rigid robots to learn self-supervised motion control using only a monocular camera. The system, developed by MIT CSAIL researchers, combines 3D scene reconstruction with embodied representation and closed-loop control.

Becoming a Robotics Engineer in 2024: A Step-by-Step Guide | Udacity
Dive deep into the field of robotics engineering, and learn the 5-step framework to landing a job in the industry, and some frequently asked questions you might have.
Introduction to Electrical Engineering and Computer Science I | Electrical Engineering and Computer Science
This course provides an integrated introduction to electrical engineering and computer science, taught using substantial laboratory experiments with mobile robots. Our primary goal is for you to learn to appreciate and use the fundamental design principles of modularity and abstraction in a variety

ROS For Beginners (ROS Noetic, Melodic, Kinetic)
Last updated 11/2025 ## What you'll learn Master ROS basics Create, build, run, and debug your ROS program Master ROS core functionalities Learn ROS best practices to make your application readable and scalable Create reusable code for any robot powered by ROS Write ROS code with both Python
[PDF] Humanoid Robots: A New Kind of Tool
In 1993, we began a project aimed at con-structing a humanoid robot for use in explor-ing theories of human intelligence.1,2 In addi-tion to the relevant engineering, computer architecture, and real-time-control issues, we’ve had to address issues particular to inte-grated systems:What types of sens

Basics of Robotics
You will learn what defines a robot, how different robot types are classified, and how they are used in industrial environments. The course covers robot kinematics, motion strategies (PTP, CP, CIRC), drive systems, end effectors, and measurement technologies. Special focus is placed on human-robot collaboration, programming principles, and practical safety in accordance with international standards such as the EU Machinery Directive and ISO 10218. Each module includes real-world examples, [...]
Robots that use these skills

SE01 Humanoid Robot
EngineAI
EngineAI SE01 is a full-size bipedal humanoid focused on smooth, human-like gait for research and industrial applications.
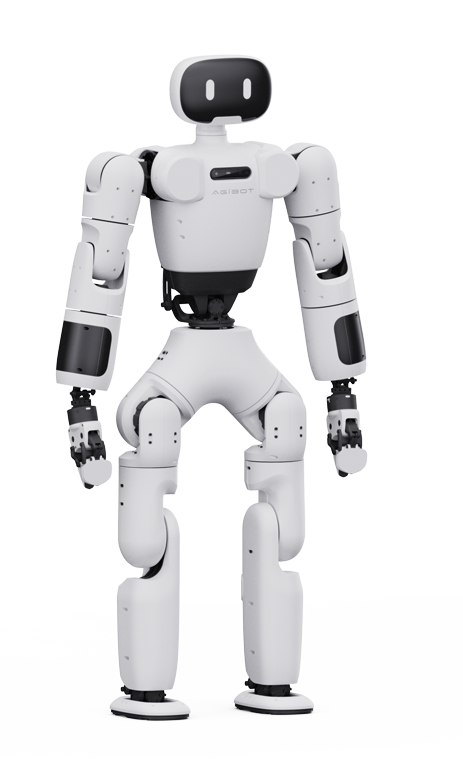
AgiBot X1
AgiBot
AgiBot X1 is a 130 cm, 33 kg open-source humanoid platform with 34 DOF for research and education.

AiNex ROS Education AI Vision Humanoid Robot
Hiwonder
AiNex is a compact ROS-enabled educational humanoid robot from Hiwonder with an HD camera for AI vision experiments.
Refer a learner and get early access to our paid pathways and 1:1 mentorship pilot.
Join referral listNew robots, industry moves, and funding in your weekly robotics briefing.
Unsubscribe anytime.