iGibson: Interactive Simulation of Large Scale Virtualized Realistic Scenes for Robot Learning
@InProceedings{pmlr-v164-li22b, title = {iGibson 2.0: Object-Centric Simulation for Robot Learning of Everyday Household Tasks}, author = {Li, Chengshu and Xia, Fei and Mart\'in-Mart\'in, Roberto and Lingelbach, Michael and Srivastava, Sanjana and Shen, Bokui and Vainio, Kent Elliott and Gokmen, Cem
Before you start
- Basic Python familiarity
- Comfort with algebra or calculus basics
- Interest in robotics systems
About this guide
@InProceedings{pmlr-v164-li22b, title = {iGibson 2.0: Object-Centric Simulation for Robot Learning of Everyday Household Tasks}, author = {Li, Chengshu and Xia, Fei and Mart'in-Mart'in, Roberto and Lingelbach, Michael and Srivastava, Sanjana and Shen, Bokui and Vainio, Kent Elliott and Gokmen, Cem and Dharan, Gokul and Jain, Tanish and Kurenkov, Andrey and Liu, Karen and Gweon, Hyowon and Wu, Jiajun and Fei-Fei, Li and Savarese, Silvio}, booktitle = {Proceedings of the 5th Conference on Robot
Common questions
What will I learn in iGibson: Interactive Simulation of Large Scale Virtualized Realistic Scenes for Robot Learning?
@InProceedings{pmlr-v164-li22b, title = {iGibson 2.0: Object-Centric Simulation for Robot Learning of Everyday Household Tasks}, author = {Li, Chengshu and Xia, Fei and Mart\'in-Mart\'in, Roberto and Lingelbach, Michael and Srivastava, Sanjana and Shen, Bokui and Vainio, Kent Ell
Is iGibson: Interactive Simulation of Large Scale Virtualized Realistic Scenes for Robot Learning free?
HumanoidHub has not verified public pricing for this guide. Open Stanford Online for the current access terms before enrolling.
Do I need any prerequisites?
Recommended prep: Basic Python familiarity; Comfort with algebra or calculus basics; Interest in robotics systems.
How long does it take?
Self-paced (provider defined). Most learners complete this guide in self-directed sessions over a few weeks.
Does it offer a certificate?
This guide does not include a formal certificate. Focus is on the learning material itself.
Related guides
Teaching Humanoid Robots Real-World Skills at MIT CSAIL’s Living Lab
Member Resources MIT In This Section Home MIT In This Section Filter Options In This Section Filter Options In This Section # Teaching Humanoid Robots Real-World Skills at MIT CSAIL’s Living Lab At MIT CSAIL's Living Lab, humanoid robots are learning to adapt, manipulate, and solve real p
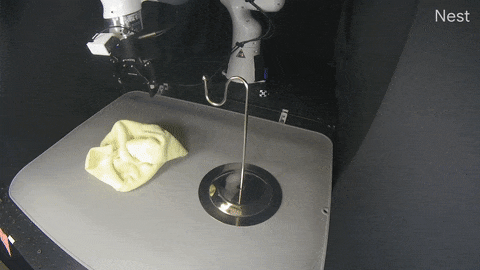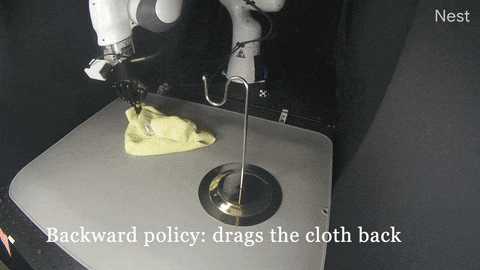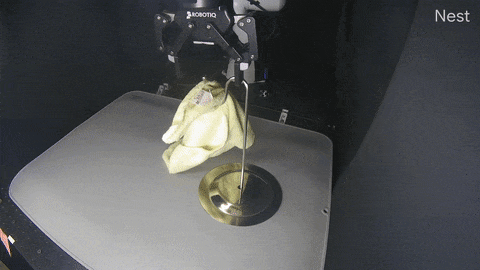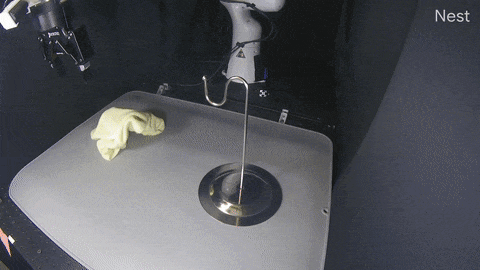
Self-Improving Robots: Embracing Autonomy in Robot Learning
The official Stanford AI Lab blog

Stanford HAI Conference Explores Robotics in a Human-Centered World: Hype, Hope, and Future Directions | Stanford HAI
Scholars zeroed in on the need for data, generalization, and better human experience.
What Is Robotics?
Get a clear answer to the question, “What is robotics?” Then, learn more information about robots and robotics, including how you can turn robotics into a career.
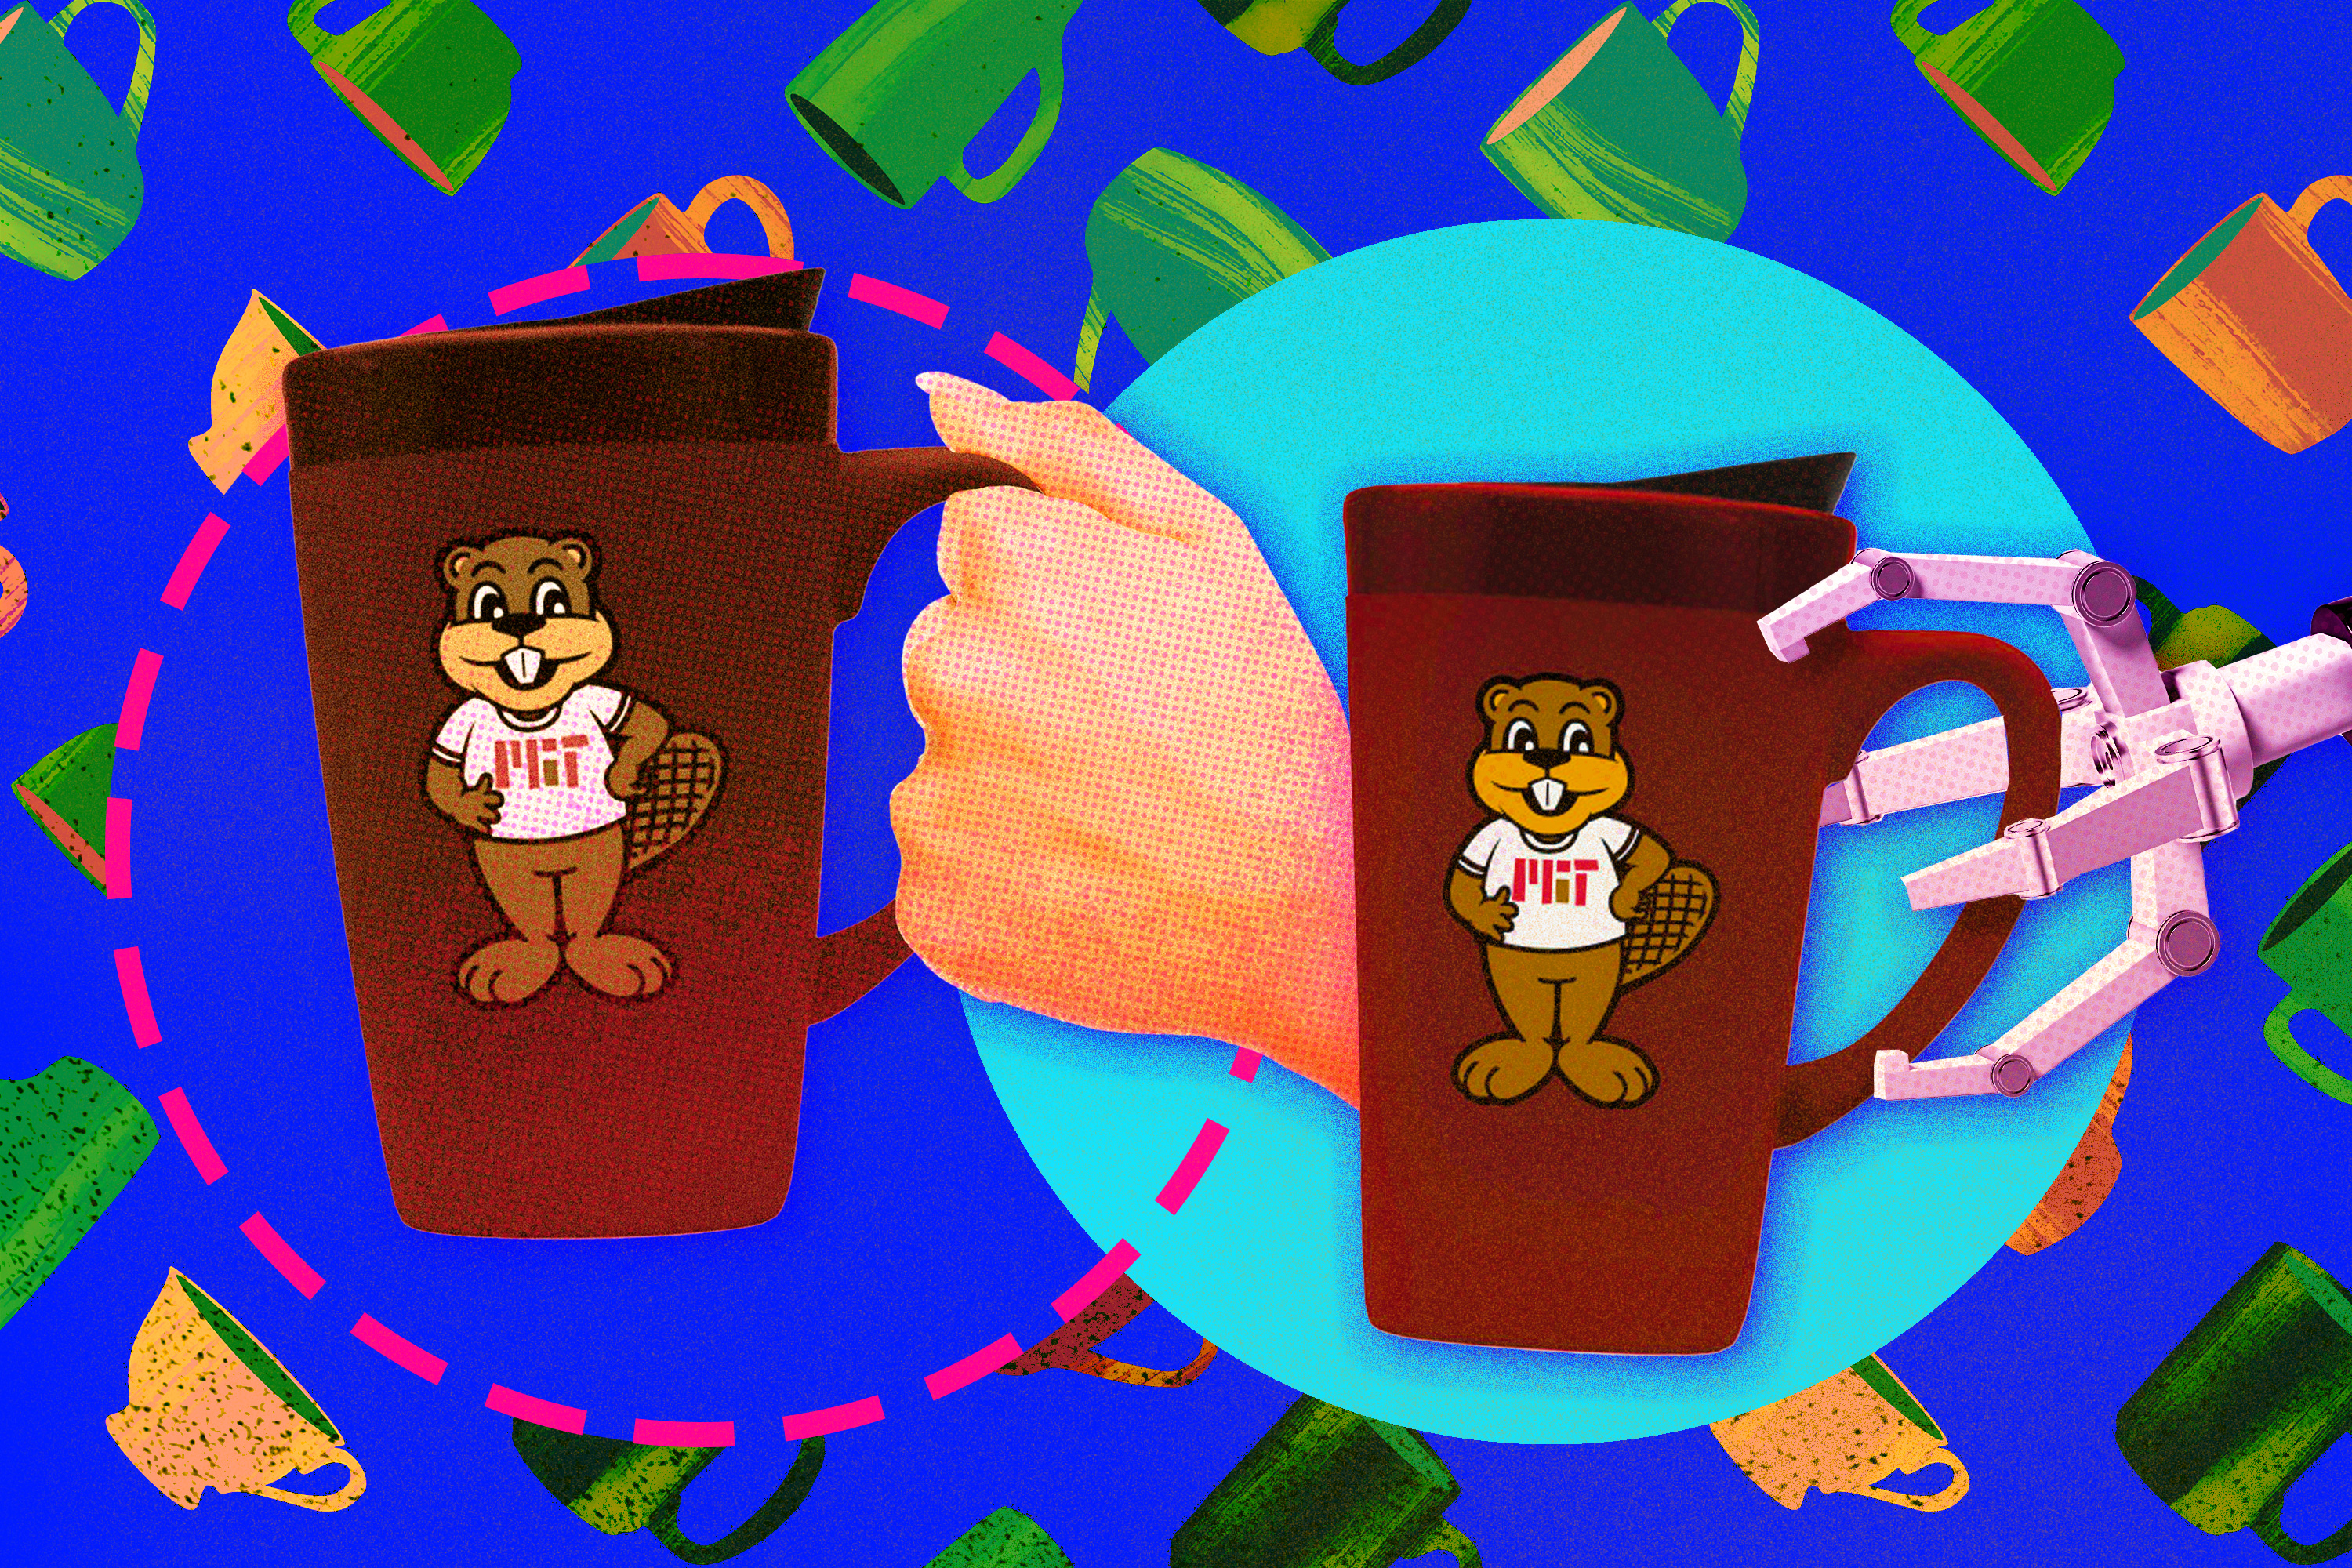
A faster way to teach a robot
A new technique enables a human to efficiently fine-tune a robot that failed to complete a desired task with very little effort on the part of the human. Their system uses algorithms, counterfactual explanations, and feedback from the user to generate synthetic data it uses to quickly fine-tune the

Expanding on Tutorials | MIT Learn
<p>Kyle Keane talks about the logistics and purpose of expanding on tutorials, and how this is related to creating, inventing, and learning.
Robots that use these skills
Robo-C 2
Promobot
Robo-C 2 is a human-shaped service robot by Promobot designed for interactive front-desk and exhibition scenarios.

ARI
PAL Robotics
ARI is a human-size wheeled service robot from PAL Robotics for human–robot interaction in public spaces and labs.
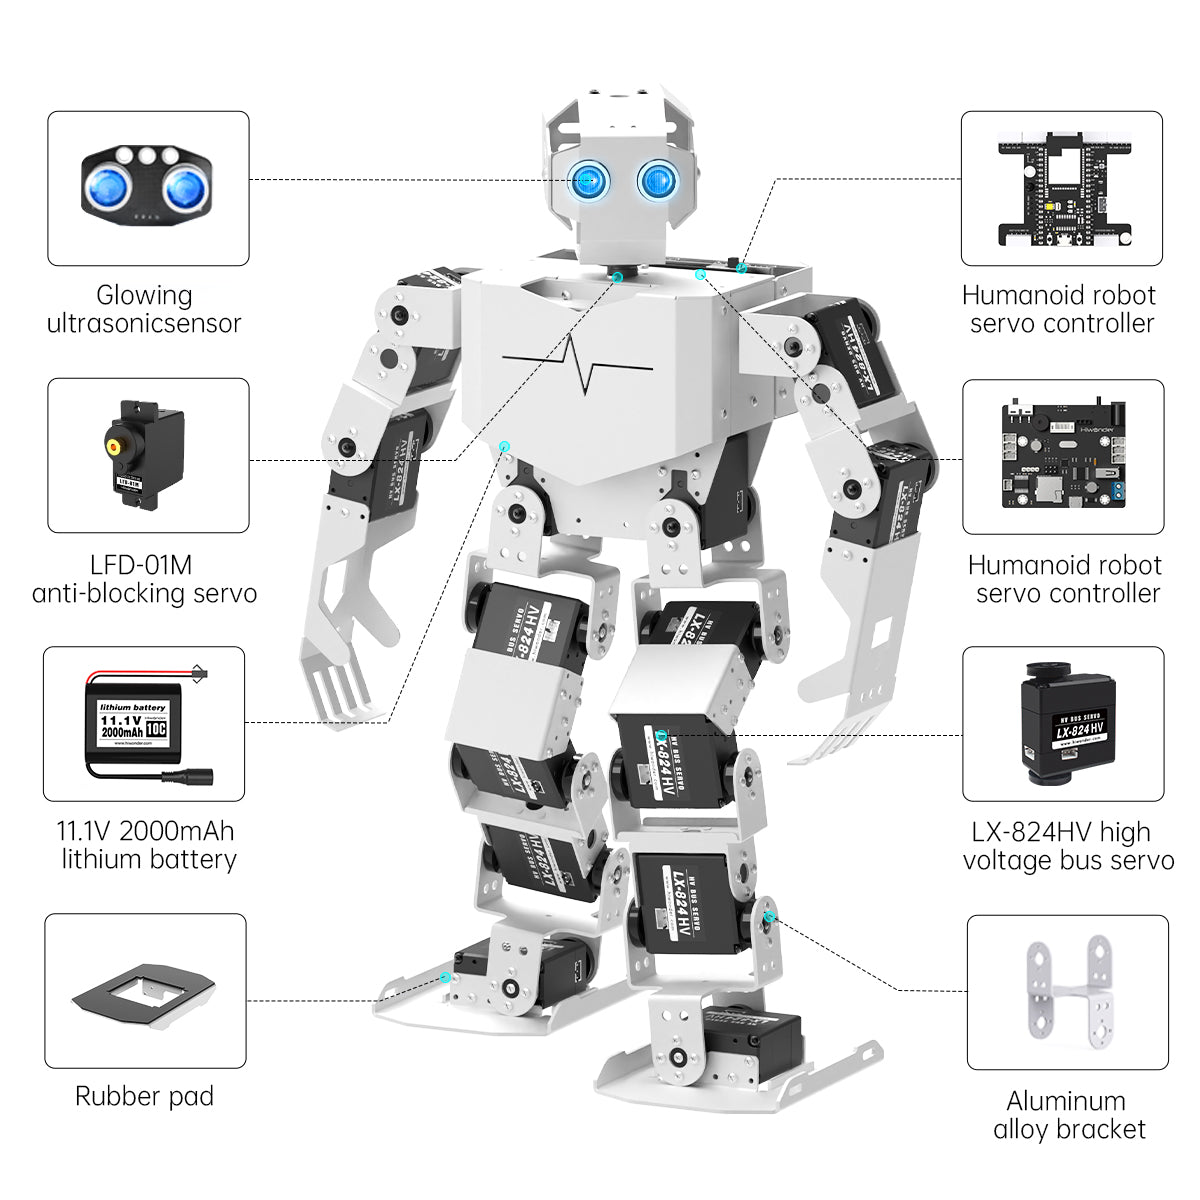
HiWonder TonyBot Humanoid Robot Kit
Hiwonder
Hiwonder TonyBot is a small humanoid (biped) robot kit for STEM learning with 16 DOF servo joints and app/program control.
Refer a learner and get early access to our paid pathways and 1:1 mentorship pilot.
Join referral listNew robots, industry moves, and funding in your weekly robotics briefing.
Unsubscribe anytime.