[PDF] An accessible, hands-on tutorial system for image-guided therapy ...
potential cases of breast or prostate cancer) on a phantom created out of standard LEGO pieces. In this way, tutorial participants work with both hardware and software while being exposed to all of the typical steps of an IGT or medical robotics procedure, including imaging, preoperative planning, t

Before you start
- Basic Python familiarity
- Comfort with algebra or calculus basics
- Interest in robotics systems
About this guide
potential cases of breast or prostate cancer) on a phantom created out of standard LEGO pieces. In this way, tutorial participants work with both hardware and software while being exposed to all of the typical steps of an IGT or medical robotics procedure, including imaging, preoperative planning, targeting and tracking, navigation and registration. 2 Materials and Methods 2.1 The tutorial supplies Table 1 lists the materials used in our image-guided therapy and medical robotics tutorial. Tutori
Common questions
What will I learn in [PDF] An accessible, hands-on tutorial system for image-guided therapy ...?
potential cases of breast or prostate cancer) on a phantom created out of standard LEGO pieces. In this way, tutorial participants work with both hardware and software while being exposed to all of the typical steps of an IGT or medical robotics procedure, including imaging, preo
Is [PDF] An accessible, hands-on tutorial system for image-guided therapy ... free?
HumanoidHub has not verified public pricing for this guide. Open MIT OpenCourseWare for the current access terms before enrolling.
Do I need any prerequisites?
Recommended prep: Basic Python familiarity; Comfort with algebra or calculus basics; Interest in robotics systems.
How long does it take?
1 hours total. Most learners complete this guide in self-directed sessions over a few weeks.
Does it offer a certificate?
This guide does not include a formal certificate. Focus is on the learning material itself.
Related guides
Programming and ZR IDE Tutorials
| For Loops | Learn to use a for loop to repeat an action a set number of times–in this case, to find the position of the second satellite and program your satellite to move toward the second satellite, but stop halfway | | Hints About SPHERES Loop Dynamics | See the effect of motion on your satel
Introduction to Robotics | MIT Department of Mechanical Engineering
laboratories include brushless DC motor control, design and fabrication of robotic arms and vehicles, robot vision and navigation, and programming and system integration using Robot Operating System (ROS). Group term project builds intelligent robots for specific applications of interest. Students t

Introduction to Yaskawa Robots with the Black Box and VEX - Udemy
This comprehensive, hands-on course dives deep into the world of Yaskawa industrial robot programming, leveraging the power and flexibility of the Black Box
ROS 2 for Beginners (ROS Jazzy - 2026)
I have created this course so you can properly learn ROS 2 from the beginning, with no prior knowledge in Robot Operating System, and without having to waste weeks, or even months, trying to find what to do. You can say goodbye to this big learning curve everyone faces when learning ROS 2. The cour

Expanding on Tutorials | MIT Learn
<p>Kyle Keane talks about the logistics and purpose of expanding on tutorials, and how this is related to creating, inventing, and learning.
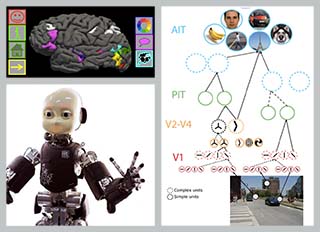
Large-Scale Incremental Learning for Robotics | Brains, Minds and Machines Summer Course | Brain and Cognitive Sciences
This resource contains information regarding brains, minds and machines summer course: Lec8-6.
Robots that use these skills

Atom
Dobot Robotics
Dobot Atom is a 1.53 m, 62 kg humanoid prototype by Dobot Robotics with 41 DOF and an AI system aimed at industrial and service tasks.
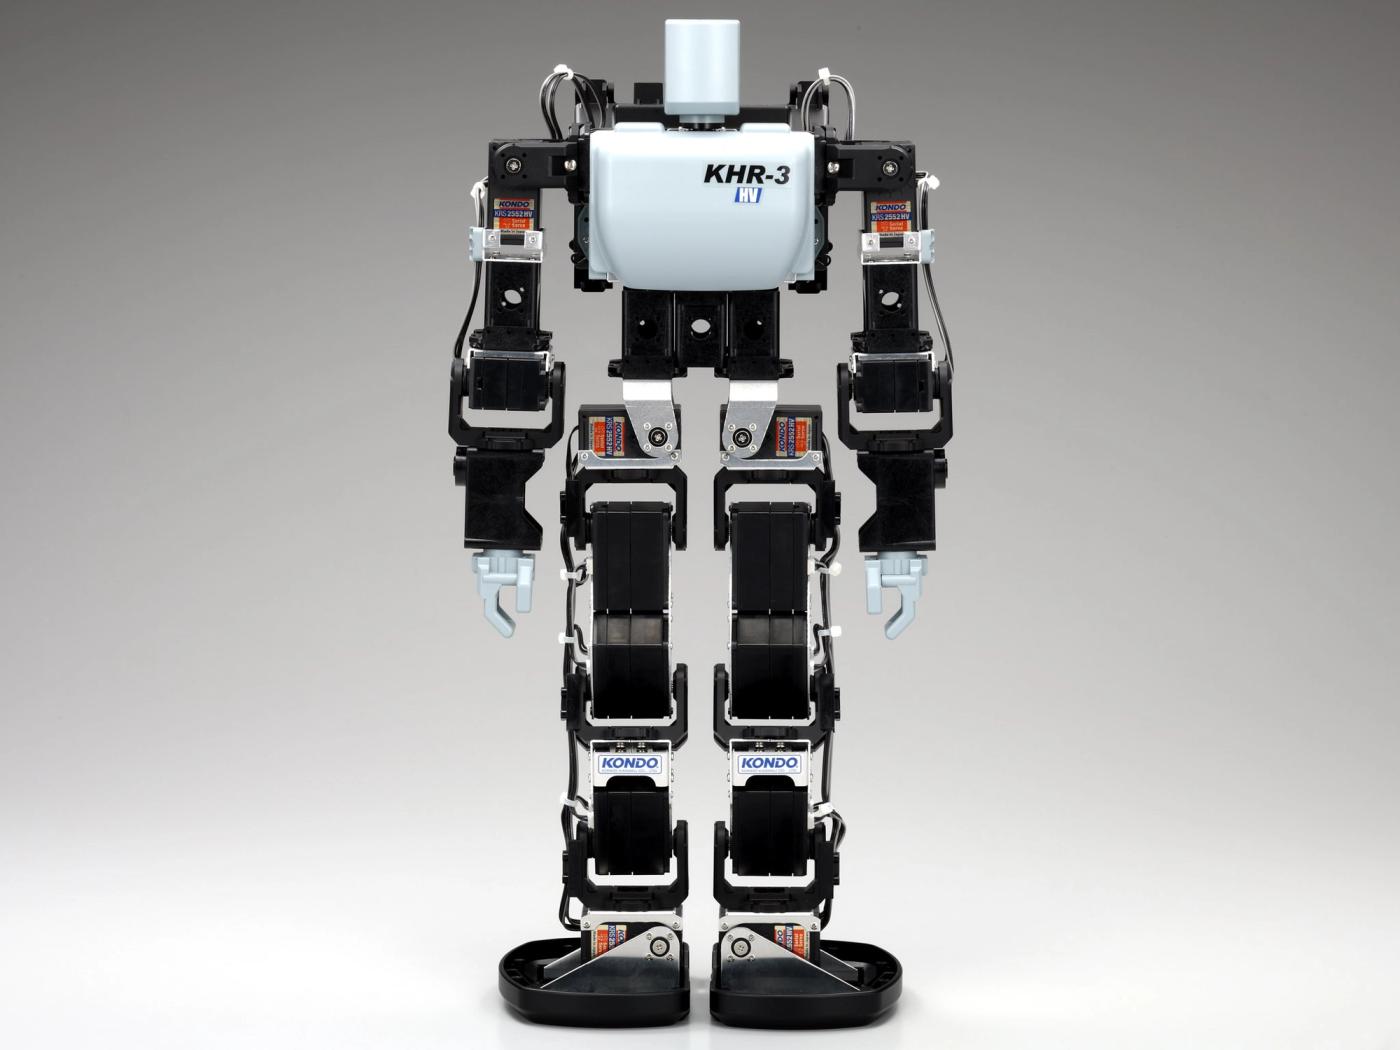
Hubo KHR-3
HUBO
HUBO KHR-3 is a prototype humanoid robot developed by KAIST’s HUBO Lab for robotics research. It is known for finger independence demonstrations such as rock‑paper‑scissors.

Robot Pi
Physical Robotics
Robot Pi (π) is an upper-body humanoid robot from Physical Robotics built for dexterous, force-controlled manipulation using multi-DOF hands.
Refer a learner and get early access to our paid pathways and 1:1 mentorship pilot.
Join referral listNew robots, industry moves, and funding in your weekly robotics briefing.
Unsubscribe anytime.