Robotics: Human-Robot Interaction - Theory and applications
This class is mainly theoretical and is open to anyone who wants to learn about the area of human-robot interaction. This applies to undergraduate and graduate engineering students, robotics researchers, as well as people working in technology and innovation companies. Instructor Juan Pablo Vásconez Ph.D. in Electronic

Before you start
- Basic Python familiarity
- Comfort with algebra or calculus basics
- Interest in robotics systems
About this guide
This class is mainly theoretical and is open to anyone who wants to learn about the area of human-robot interaction. This applies to undergraduate and graduate engineering students, robotics researchers, as well as people working in technology and innovation companies.
Instructor
Juan Pablo Vásconez
Ph.D. in Electronic Engineering
4.8 Instructor Rating 108 Reviews 3,416 Students 2 Courses [...] Teaching & AcademicsEngineeringRobotics
Robotics: Human-Robot Interaction - Theory and a
Common questions
What will I learn in Robotics: Human-Robot Interaction - Theory and applications?
This class is mainly theoretical and is open to anyone who wants to learn about the area of human-robot interaction. This applies to undergraduate and graduate engineering students, robotics researchers, as well as people working in technology and innovation companies. Instructor
Is Robotics: Human-Robot Interaction - Theory and applications free?
HumanoidHub has not verified public pricing for this guide. Open Udemy for the current access terms before enrolling.
Do I need any prerequisites?
Recommended prep: Basic Python familiarity; Comfort with algebra or calculus basics; Interest in robotics systems.
How long does it take?
Self-paced (provider defined). Most learners complete this guide in self-directed sessions over a few weeks.
Does it offer a certificate?
This guide does not include a formal certificate. Focus is on the learning material itself.
Related guides

[PDF] Humanoid Robots: A New Kind of Tool
In 1993, we began a project aimed at con-structing a humanoid robot for use in explor-ing theories of human intelligence.1,2 In addi-tion to the relevant engineering, computer architecture, and real-time-control issues, we’ve had to address issues particular to inte-grated systems:What types of sens
Precision home robots learn with real-to-sim-to-real - MIT EECS
- Biological and Medical Devices and Systems - Communications Systems - Computational Fabrication and Manufacturing - Computer Architecture - Educational Technology - Electronic, Magnetic, Optical and Quantum Materials and Devices - Energy - Graphics and Vision - Huma
A faster way to teach a robot
A new technique enables a human to efficiently fine-tune a robot that failed to complete a desired task with very little effort on the part of the human. Their system uses algorithms, counterfactual explanations, and feedback from the user to generate synthetic data it uses to quickly fine-tune the
How to Get Into Robotics
In this course, you will learn about the dynamic world of robotics, which blends engineering, electronics, and computer science to create innovations that enhance our daily lives. You'll learn to envision a future where humanoid robots assist the elderly, autonomous cars ensure safety and medical
Robot, know thyself: New vision-based system teaches machines to understand their bodies
A vision-based control system called Neural Jacobian Fields enables soft and rigid robots to learn self-supervised motion control using only a monocular camera. The system, developed by MIT CSAIL researchers, combines 3D scene reconstruction with embodied representation and closed-loop control.
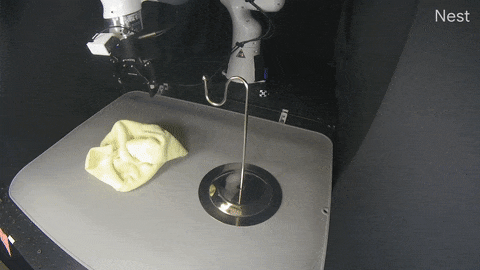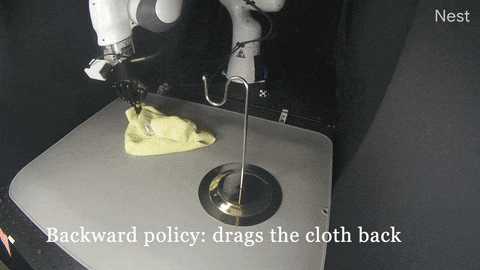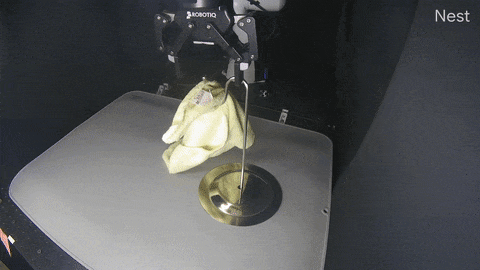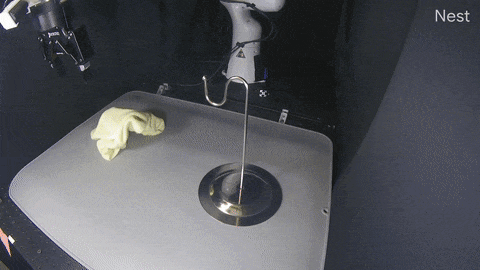
Self-Improving Robots: Embracing Autonomy in Robot Learning
The official Stanford AI Lab blog
Robots that use these skills
Sophia
Hanson Robotics
Sophia is a Hanson Robotics social humanoid designed for human-robot interaction with expressive facial animations and conversational AI.
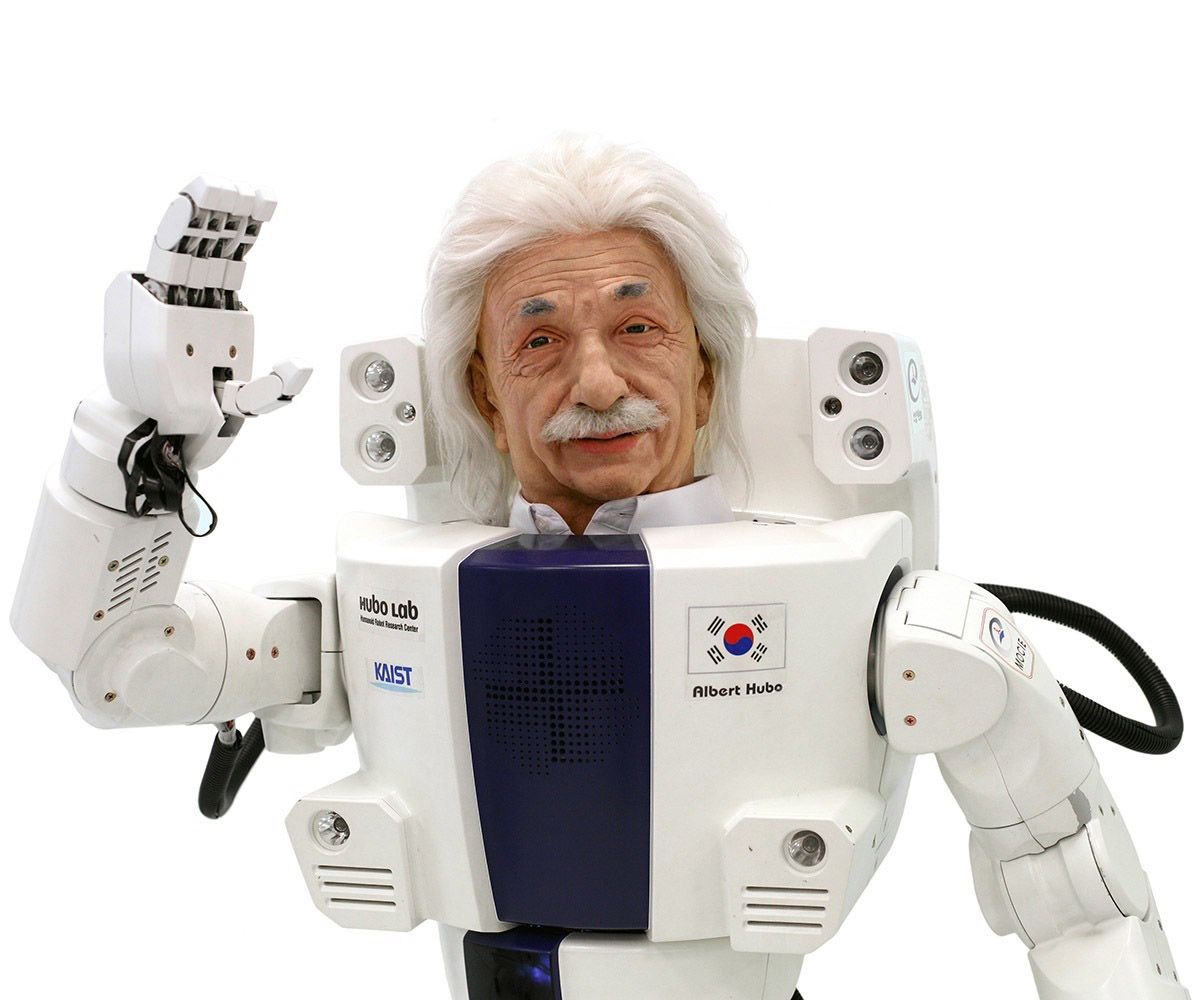
Albert Hubo
HUBO
Albert HUBO is a KAIST HUBO-platform humanoid with an expressive Einstein-like animatronic head for HRI demos and research.

Ami Desktop
Engineered Arts
Ami Desktop is a stationary, desktop-sized expressive robot head from Engineered Arts for HRI and conversational AI research and education.
Refer a learner and get early access to our paid pathways and 1:1 mentorship pilot.
Join referral listNew robots, industry moves, and funding in your weekly robotics briefing.
Unsubscribe anytime.