Using generative AI to diversify virtual training grounds for robots
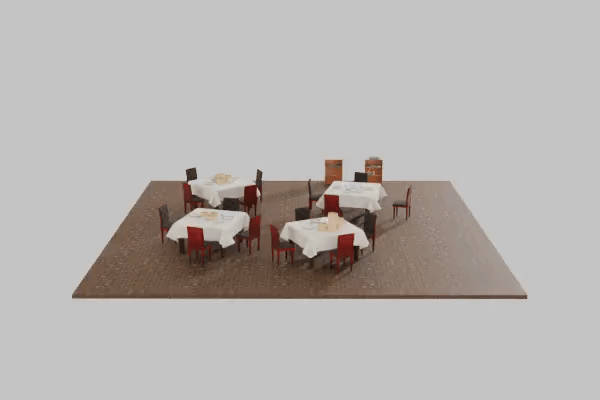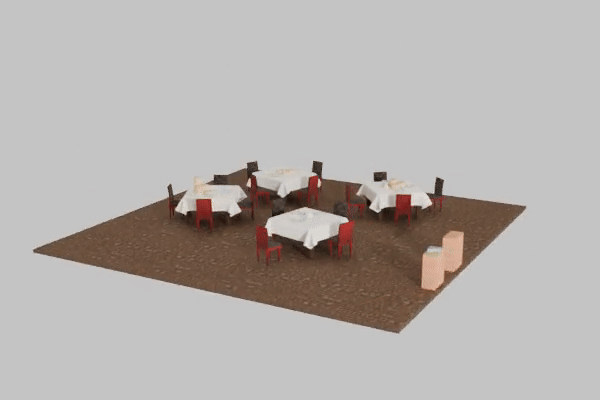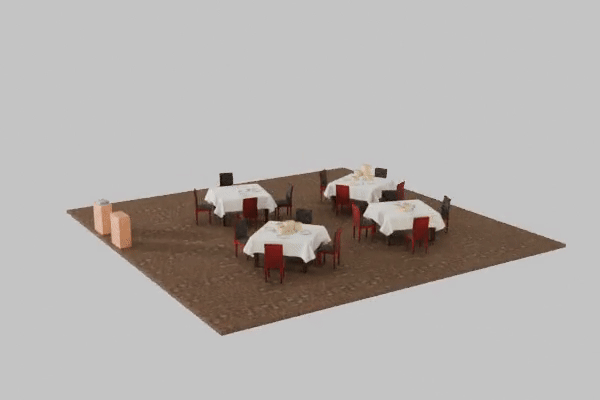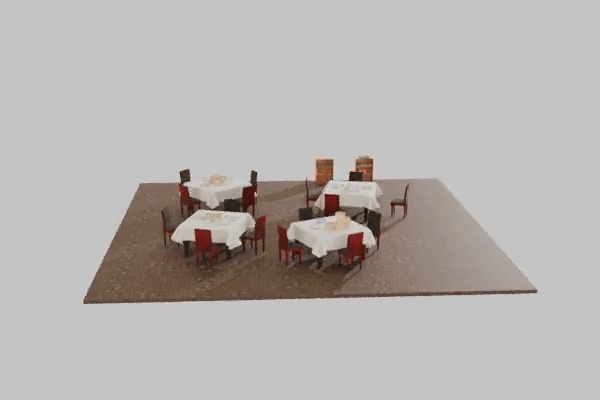
MIT CSAIL&039;s “Steerable Scene Generation” method helps create realistic, virtual training grounds to help robots practice physical tasks. It arranges 3D assets into digital kitchens, living rooms, and restaurants, then refines them to be physically accurate to ensure they&039;re lifelik
Before you start
- Basic Python familiarity
- Comfort with algebra or calculus basics
- Interest in robotics systems
About this guide
MIT CSAIL's “Steerable Scene Generation” method helps create realistic, virtual training grounds to help robots practice physical tasks. It arranges 3D assets into digital kitchens, living rooms, and restaurants, then refines them to be physically accurate to ensure they're lifelike.
Common questions
What will I learn in Using generative AI to diversify virtual training grounds for robots?
MIT CSAIL&039;s “Steerable Scene Generation” method helps create realistic, virtual training grounds to help robots practice physical tasks. It arranges 3D assets into digital kitchens, living rooms, and restaurants, then refines them to be physically accurate to ensure they&
Is Using generative AI to diversify virtual training grounds for robots free?
HumanoidHub has not verified public pricing for this guide. Open MIT OpenCourseWare for the current access terms before enrolling.
Do I need any prerequisites?
Recommended prep: Basic Python familiarity; Comfort with algebra or calculus basics; Interest in robotics systems.
How long does it take?
1 hours total. Most learners complete this guide in self-directed sessions over a few weeks.
Does it offer a certificate?
This guide does not include a formal certificate. Focus is on the learning material itself.
Related guides

[PDF] Humanoid Robots: A New Kind of Tool
In 1993, we began a project aimed at con-structing a humanoid robot for use in explor-ing theories of human intelligence.1,2 In addi-tion to the relevant engineering, computer architecture, and real-time-control issues, we’ve had to address issues particular to inte-grated systems:What types of sens
Precision home robots learn with real-to-sim-to-real - MIT EECS
- Biological and Medical Devices and Systems - Communications Systems - Computational Fabrication and Manufacturing - Computer Architecture - Educational Technology - Electronic, Magnetic, Optical and Quantum Materials and Devices - Energy - Graphics and Vision - Huma
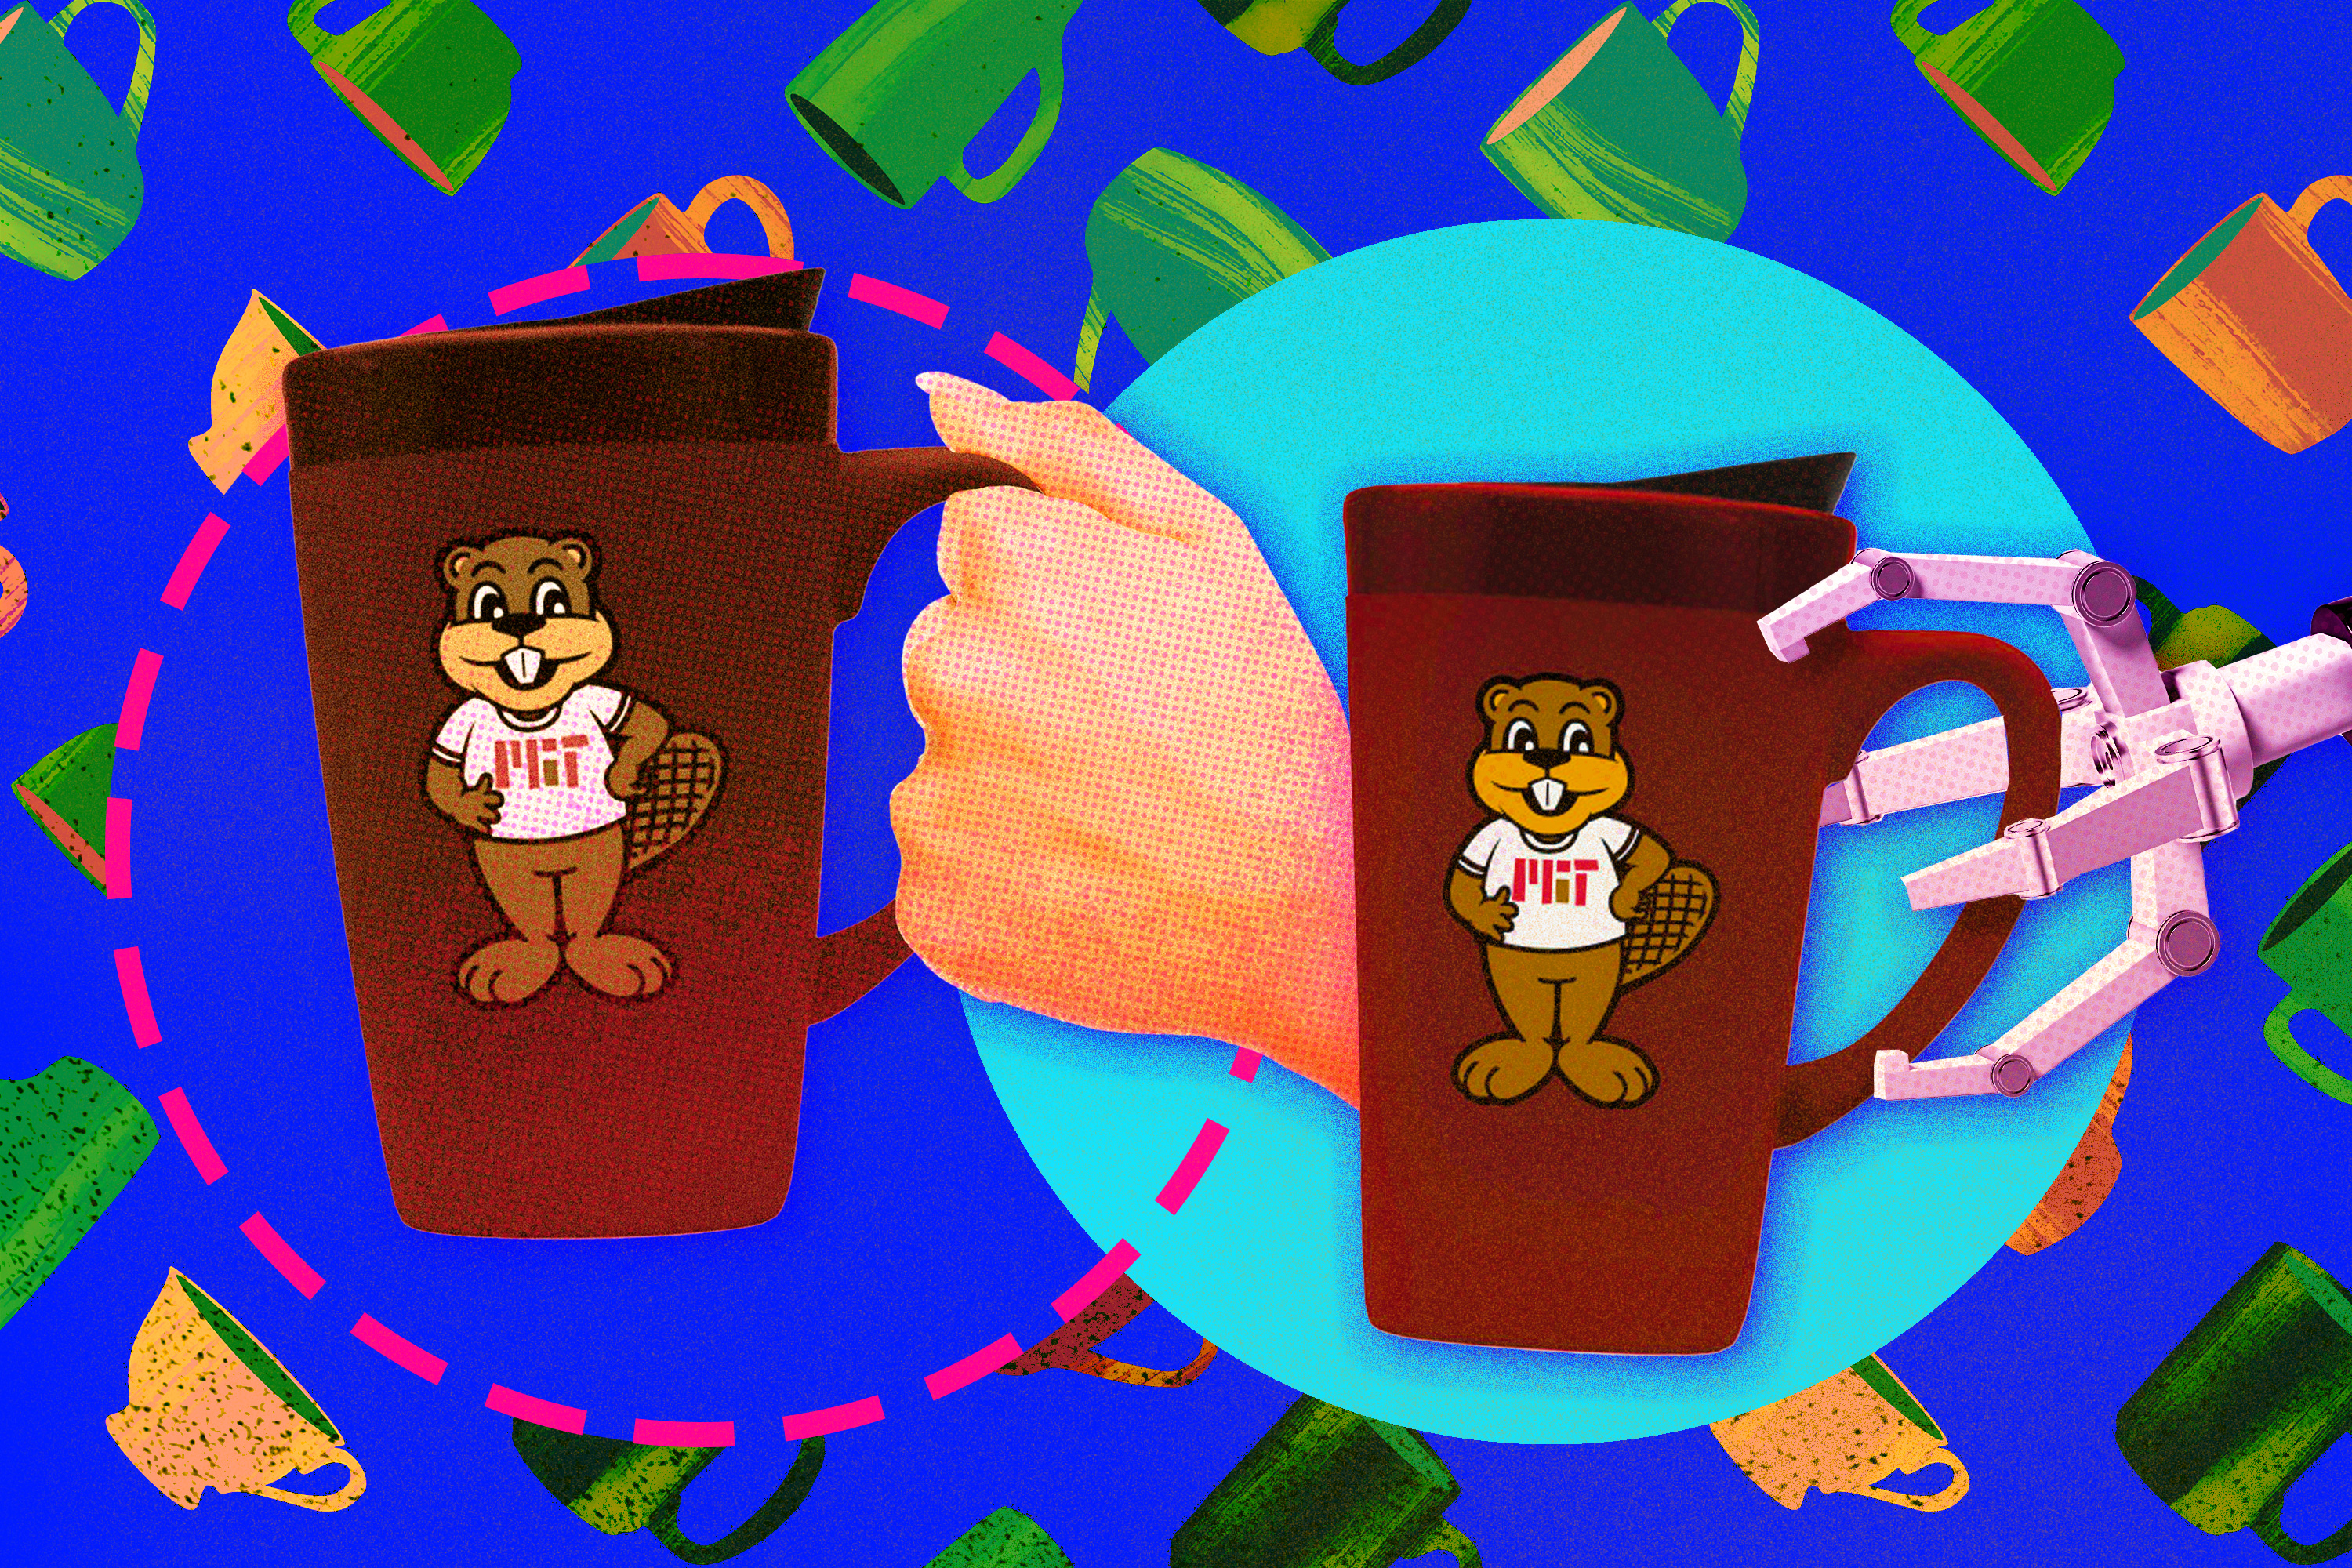
A faster way to teach a robot
A new technique enables a human to efficiently fine-tune a robot that failed to complete a desired task with very little effort on the part of the human. Their system uses algorithms, counterfactual explanations, and feedback from the user to generate synthetic data it uses to quickly fine-tune the
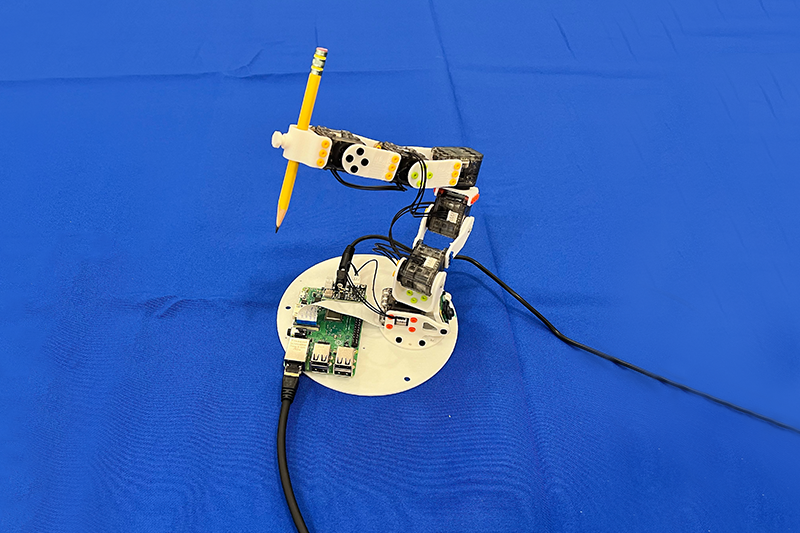
Robot, know thyself: New vision-based system teaches machines to understand their bodies
A vision-based control system called Neural Jacobian Fields enables soft and rigid robots to learn self-supervised motion control using only a monocular camera. The system, developed by MIT CSAIL researchers, combines 3D scene reconstruction with embodied representation and closed-loop control.
Teaching Humanoid Robots Real-World Skills at MIT CSAIL’s Living Lab
Member Resources MIT In This Section Home MIT In This Section Filter Options In This Section Filter Options In This Section # Teaching Humanoid Robots Real-World Skills at MIT CSAIL’s Living Lab At MIT CSAIL's Living Lab, humanoid robots are learning to adapt, manipulate, and solve real p
Unit 8. Robotics | Brains, Minds and Machines Summer Course | Brain and Cognitive Sciences
This page summarizes the unit topic and activities, and links to lecture videos, notes and further study resources.
Robots that use these skills

HMND 01 Alpha
Humanoid
HMND 01 Alpha is a humanoid-style robot on a wheeled base referenced in a 2025–2026 third-party comparison of humanoid robots. Public, verifiable specs and commercial details are not disclosed in that source.
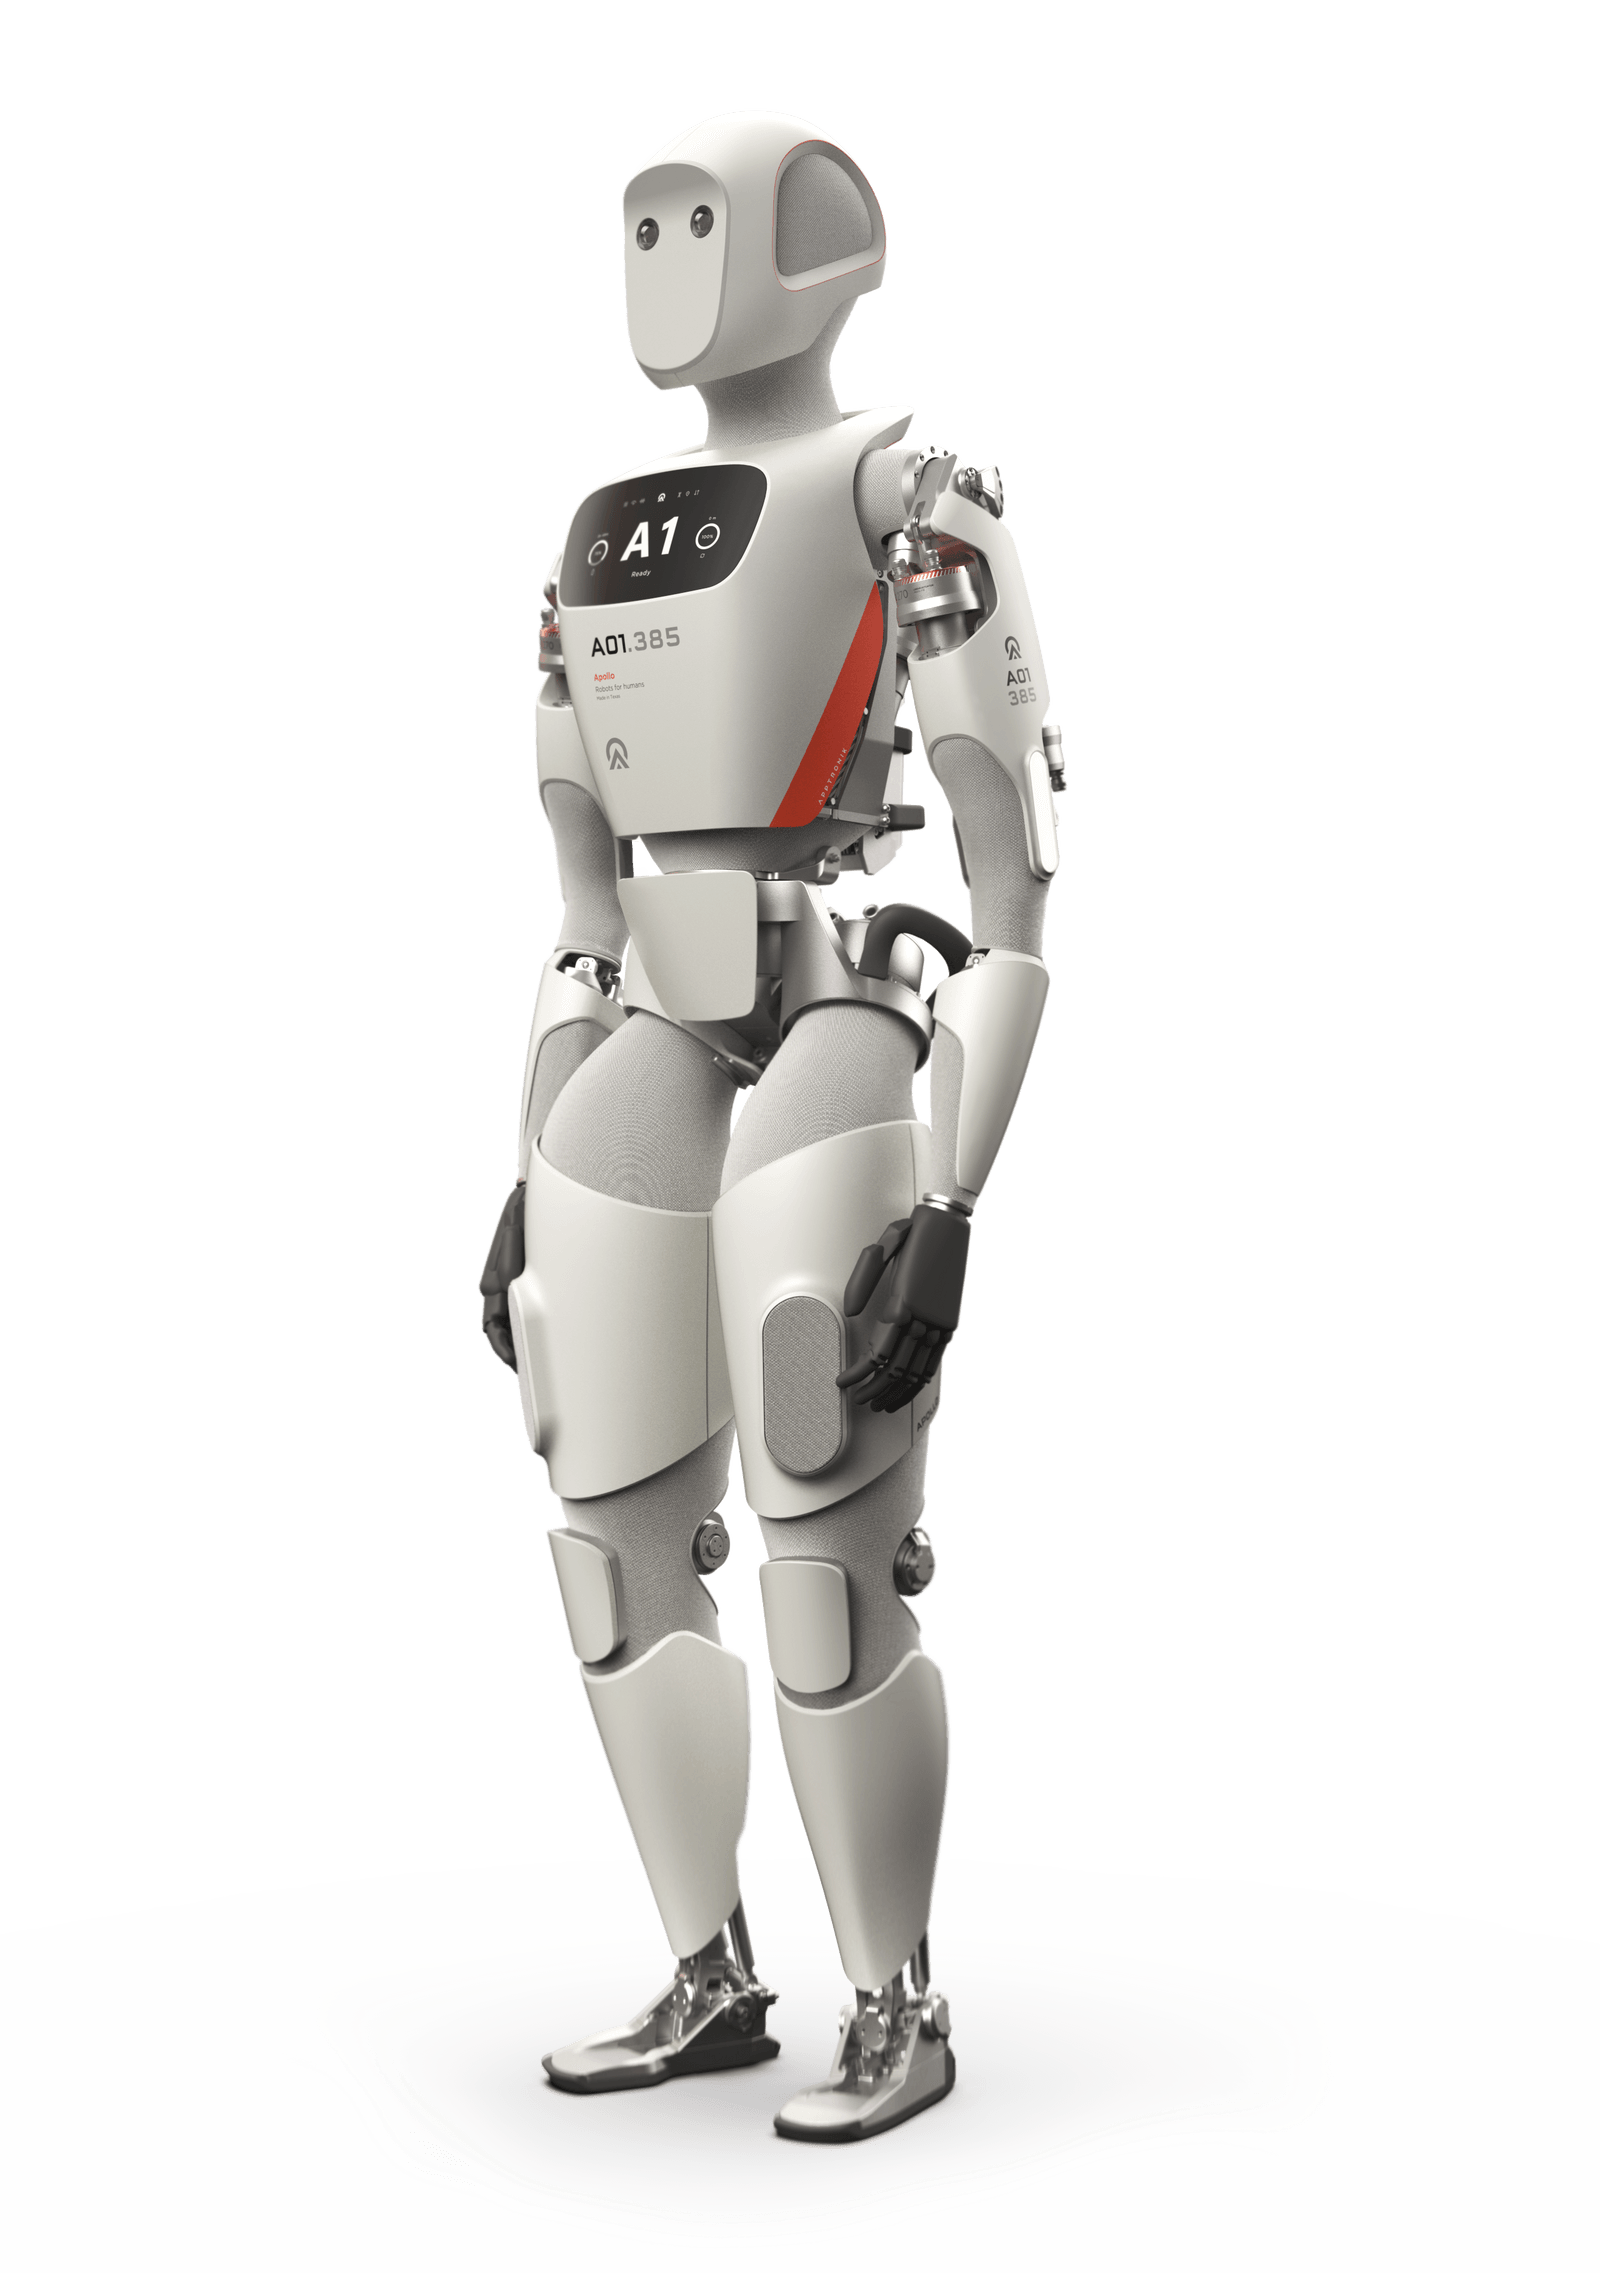
Apollo
Apptronik
Apollo is a bipedal humanoid robot from Apptronik aimed at automating tasks in industrial and commercial environments.

Figure 01
Figure AI
Figure 01 is Figure AI’s first humanoid robot prototype for general-purpose labor in indoor commercial and industrial spaces.
Refer a learner and get early access to our paid pathways and 1:1 mentorship pilot.
Join referral listNew robots, industry moves, and funding in your weekly robotics briefing.
Unsubscribe anytime.