Ch. 2 - Let's get you a robot - Robotic Manipulation
short of adding tire mechanics into our physics engine. We also have a number of examples of this workflow in my Underactuated Robotics course, where we make extensive use of "simple models". [...] Hydraulic actuators provide another solution for generating large torques without large transmissions.

Before you start
- Basic Python familiarity
- Comfort with algebra or calculus basics
- Interest in robotics systems
About this guide
short of adding tire mechanics into our physics engine. We also have a number of examples of this workflow in my Underactuated Robotics course, where we make extensive use of "simple models". [...] Hydraulic actuators provide another solution for generating large torques without large transmissions. Sarcos had a series of torque-controlled arms (and humanoids), and many of the most famous robots from Boston Dynamics are based on hydraulics (though there is an increasing trend towards electric mo
Common questions
What will I learn in Ch. 2 - Let's get you a robot - Robotic Manipulation?
short of adding tire mechanics into our physics engine. We also have a number of examples of this workflow in my Underactuated Robotics course, where we make extensive use of "simple models". [...] Hydraulic actuators provide another solution for generating large torques without
Is Ch. 2 - Let's get you a robot - Robotic Manipulation free?
HumanoidHub has not verified public pricing for this guide. Open MIT OpenCourseWare for the current access terms before enrolling.
Do I need any prerequisites?
Recommended prep: Basic Python familiarity; Comfort with algebra or calculus basics; Interest in robotics systems.
How long does it take?
Self-paced (provider defined). Most learners complete this guide in self-directed sessions over a few weeks.
Does it offer a certificate?
This guide does not include a formal certificate. Focus is on the learning material itself.
Related guides
A faster way to teach a robot
A new technique enables a human to efficiently fine-tune a robot that failed to complete a desired task with very little effort on the part of the human. Their system uses algorithms, counterfactual explanations, and feedback from the user to generate synthetic data it uses to quickly fine-tune the
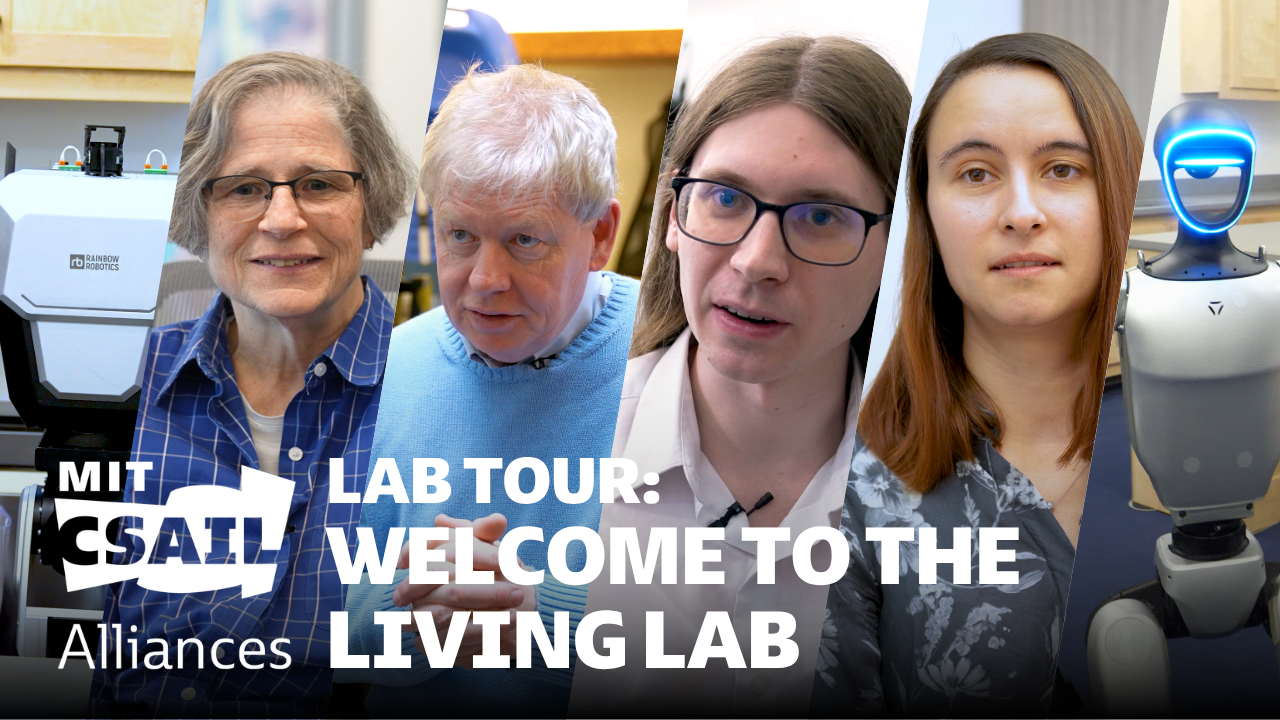
Teaching Humanoid Robots Real-World Skills at MIT CSAIL’s Living Lab
Member Resources MIT In This Section Home MIT In This Section Filter Options In This Section Filter Options In This Section # Teaching Humanoid Robots Real-World Skills at MIT CSAIL’s Living Lab At MIT CSAIL's Living Lab, humanoid robots are learning to adapt, manipulate, and solve real p
Unit 8. Robotics | Brains, Minds and Machines Summer Course | Brain and Cognitive Sciences
This page summarizes the unit topic and activities, and links to lecture videos, notes and further study resources.
[PDF] 1st Reading - Personal Robots Group
5.6. Learning results The tutoring of tasks exemplifies our approach to teaching as a collaborative interac-tion. Joint attention is established both on the object level and on the task structure level. The robot uses subtle expression to indicate to the human tutor when it is ready to learn somethin
[PDF] Children, Humanoid Robots and Caregivers - MIT CSAIL
Conclusions This paper described a framework for developmental object perception and learning on a humanoid robot, which aims at teaching humanoids as children. We described algorithms to learn about the robot’s self appearance and its surrounding world. The epige-netic principle established the fou
[PDF] Foundations for a Theory of Mind for a Humanoid Robot - Research
• Chapter 8 : Detecting Faces and Head Pose One final primitive perceptual process will be required. The robot will need to find human faces in the visual scene and to extract the orientation of the head as a measurement of where that person is attending. This orientation direction will be used later
Robots that use these skills
Atom Max
Dobot Robotics
DOBOT ATOM is Dobot Robotics’ first full-size humanoid robot aimed at embodied AI research and cross-scenario industrial/commercial task automation.
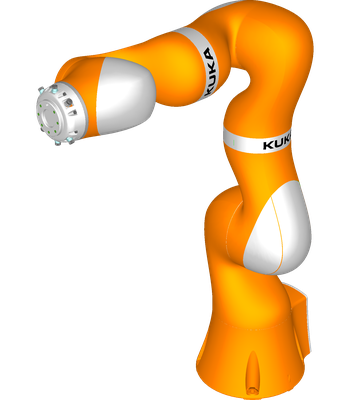
LBR iiwa 14 R820
KUKA
KUKA LBR iiwa 14 R820 is a 7-axis collaborative industrial robot arm with a 14 kg payload and ~820 mm reach.

Robot Pi
Physical Robotics
Robot Pi (π) is an upper-body humanoid robot from Physical Robotics built for dexterous, force-controlled manipulation using multi-DOF hands.
Refer a learner and get early access to our paid pathways and 1:1 mentorship pilot.
Join referral listNew robots, industry moves, and funding in your weekly robotics briefing.
Unsubscribe anytime.