[PDF] Robots for the Human and Interactive Simulations - Stanford University
This framework was integrated with our haptic render-ing system to provide a general environment for interac-tive haptic dynamic simulation. Figure 2 shows a user hap-tically interacting with a simulated humanoid robot. The haptic device serves as a 3D position input and force output device. By movi
Before you start
- Basic Python familiarity
- Comfort with algebra or calculus basics
- Interest in robotics systems
About this guide
This framework was integrated with our haptic render-ing system to provide a general environment for interac-tive haptic dynamic simulation. Figure 2 shows a user hap-tically interacting with a simulated humanoid robot. The haptic device serves as a 3D position input and force output device. By moving the end-effector of the haptic device, the user is able to specify a manipulation task for the humanoid robot in real time. At the same time the force output of the device is used to reflect the ine
Common questions
What will I learn in [PDF] Robots for the Human and Interactive Simulations - Stanford University?
This framework was integrated with our haptic render-ing system to provide a general environment for interac-tive haptic dynamic simulation. Figure 2 shows a user hap-tically interacting with a simulated humanoid robot. The haptic device serves as a 3D position input and force ou
Is [PDF] Robots for the Human and Interactive Simulations - Stanford University free?
HumanoidHub has source-backed pricing for this guide. Stanford Online sets current rates, so open the provider link for checkout details and any discounts.
Do I need any prerequisites?
Recommended prep: Basic Python familiarity; Comfort with algebra or calculus basics; Interest in robotics systems.
How long does it take?
1 hours total. Most learners complete this guide in self-directed sessions over a few weeks.
Does it offer a certificate?
This guide does not include a formal certificate. Focus is on the learning material itself.
Related guides

Stanford HAI Conference Explores Robotics in a Human-Centered World: Hype, Hope, and Future Directions | Stanford HAI
Scholars zeroed in on the need for data, generalization, and better human experience.
A faster way to teach a robot
A new technique enables a human to efficiently fine-tune a robot that failed to complete a desired task with very little effort on the part of the human. Their system uses algorithms, counterfactual explanations, and feedback from the user to generate synthetic data it uses to quickly fine-tune the
Join
Building generative models for motion synthesis or control Experimenting with humanoids, robot arms, exoskeletons and dexterous hands Training virtual agents using RL and transfer to real robots Collecting data with different motion capture systems Pre-training or fine-tuning VLMs for policy dev
Unit 8. Robotics | Brains, Minds and Machines Summer Course | Brain and Cognitive Sciences
This page summarizes the unit topic and activities, and links to lecture videos, notes and further study resources.

[PDF] Children, Humanoid Robots and Caregivers - MIT CSAIL
Conclusions This paper described a framework for developmental object perception and learning on a humanoid robot, which aims at teaching humanoids as children. We described algorithms to learn about the robot’s self appearance and its surrounding world. The epige-netic principle established the fou
[PDF] Foundations for a Theory of Mind for a Humanoid Robot - Research
• Chapter 8 : Detecting Faces and Head Pose One final primitive perceptual process will be required. The robot will need to find human faces in the visual scene and to extract the orientation of the head as a measurement of where that person is attending. This orientation direction will be used later
Robots that use these skills
Albert Hubo
HUBO
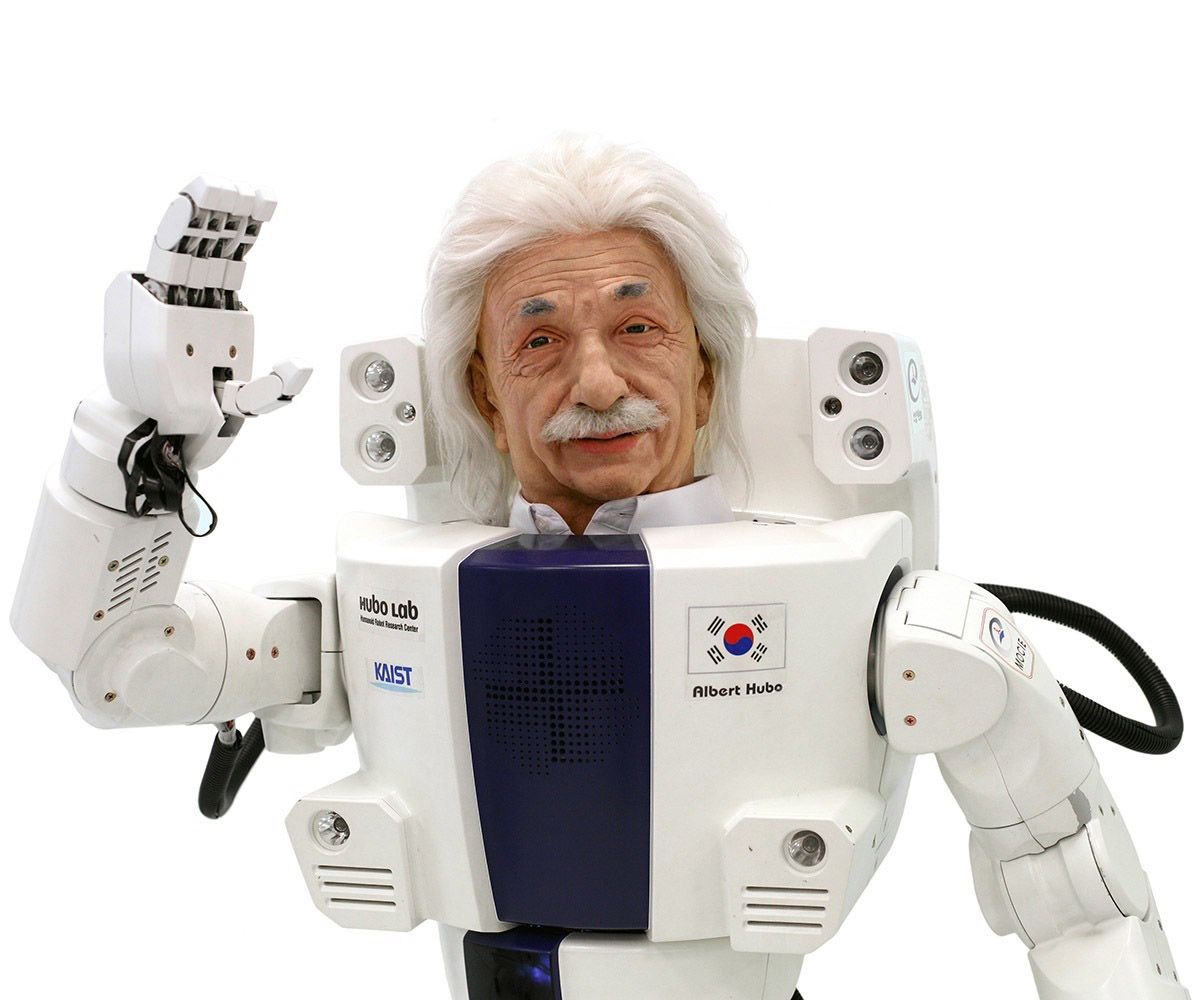
Albert HUBO is a KAIST HUBO-platform humanoid with an expressive Einstein-like animatronic head for HRI demos and research.

ARI
PAL Robotics
ARI is a human-size wheeled service robot from PAL Robotics for human–robot interaction in public spaces and labs.
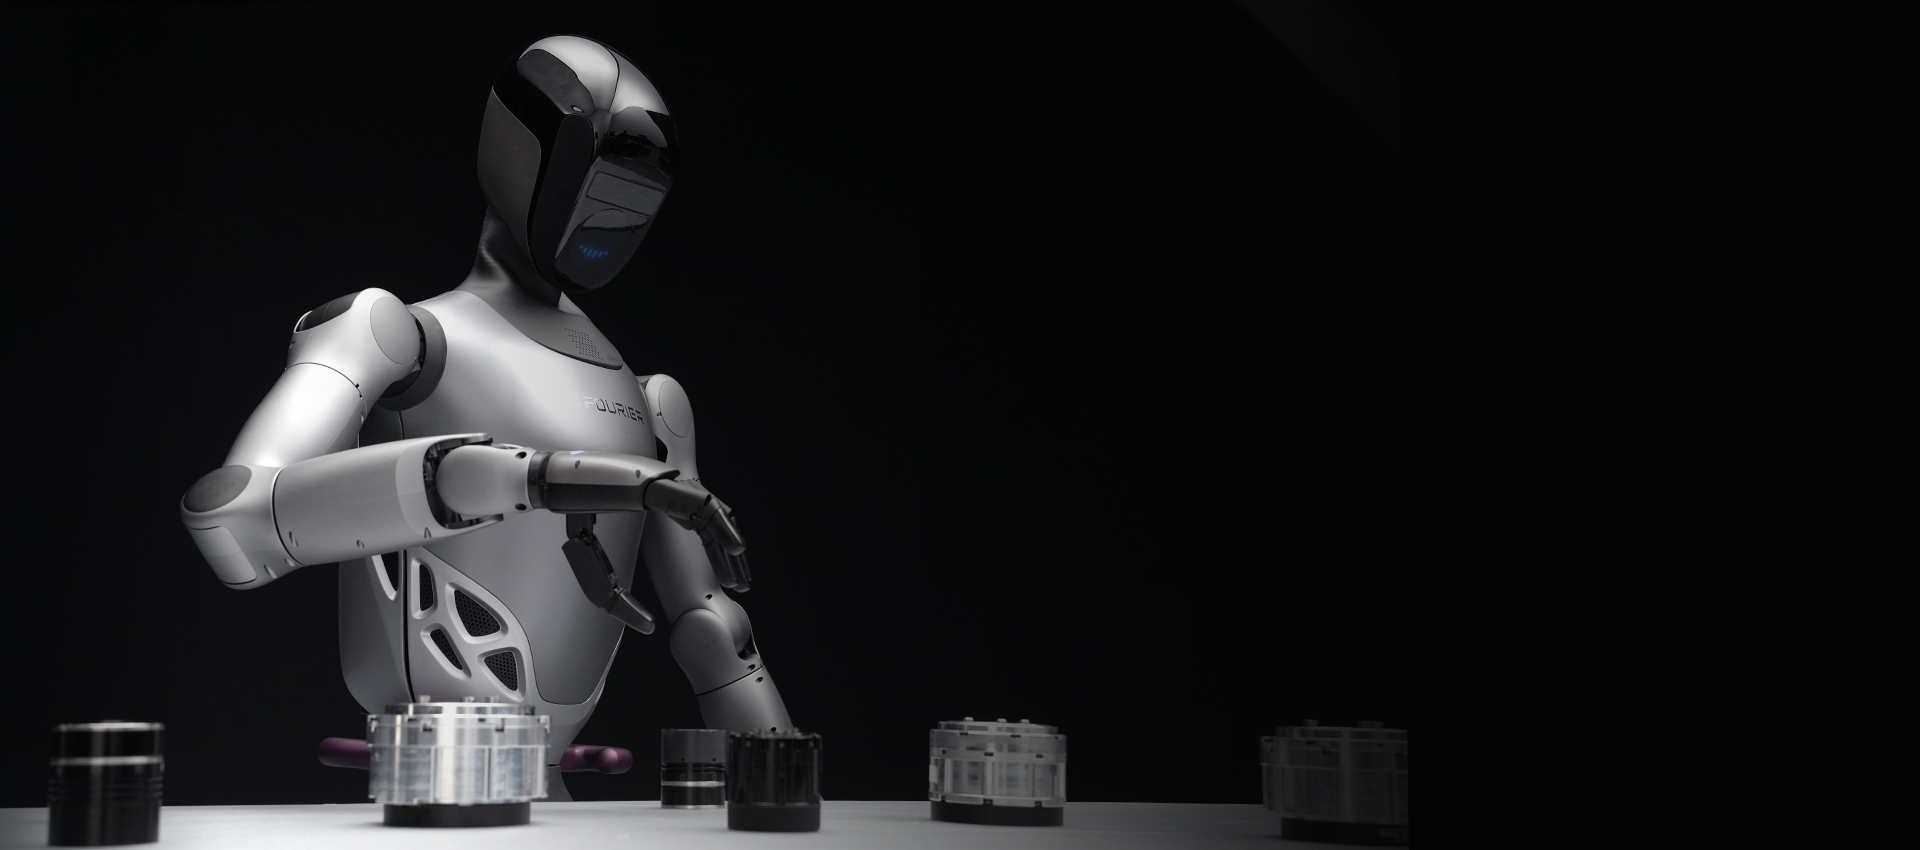
GR-2 Humanoid
Fourier Intelligence
Fourier Intelligence GR-2 is a bipedal humanoid robot platform in the GRx series intended for embodied AI research and application development.
Refer a learner and get early access to our paid pathways and 1:1 mentorship pilot.
Join referral listNew robots, industry moves, and funding in your weekly robotics briefing.
Unsubscribe anytime.