Underactuated Robotics
course is to help you discover this structure, and to learn how to use this structure to develop stronger algorithms and to guide your scientific endeavors into learning-based control. [...] Today, the conversations about reinforcement learning (RL) are loud and passionate enough to drown out almost

Before you start
- Basic Python familiarity
- Comfort with algebra or calculus basics
- Interest in robotics systems
About this guide
course is to help you discover this structure, and to learn how to use this structure to develop stronger algorithms and to guide your scientific endeavors into learning-based control. [...] Today, the conversations about reinforcement learning (RL) are loud and passionate enough to drown out almost every other conversation in the room. Ironically, now I am the older professor and I find myself still believing in RL, but not with the complete faith of my youth. There is so much one can understan
Common questions
What will I learn in Underactuated Robotics?
course is to help you discover this structure, and to learn how to use this structure to develop stronger algorithms and to guide your scientific endeavors into learning-based control. [...] Today, the conversations about reinforcement learning (RL) are loud and passionate enough
Is Underactuated Robotics free?
HumanoidHub has not verified public pricing for this guide. Open MIT OpenCourseWare for the current access terms before enrolling.
Do I need any prerequisites?
Recommended prep: Basic Python familiarity; Comfort with algebra or calculus basics; Interest in robotics systems.
How long does it take?
Self-paced (provider defined). Most learners complete this guide in self-directed sessions over a few weeks.
Does it offer a certificate?
This guide does not include a formal certificate. Focus is on the learning material itself.
Related guides

Expanding on Tutorials | MIT Learn
<p>Kyle Keane talks about the logistics and purpose of expanding on tutorials, and how this is related to creating, inventing, and learning.
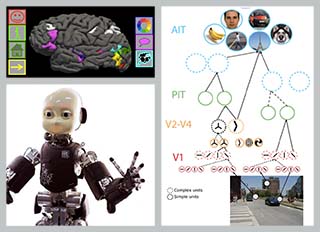
Large-Scale Incremental Learning for Robotics | Brains, Minds and Machines Summer Course | Brain and Cognitive Sciences
This resource contains information regarding brains, minds and machines summer course: Lec8-6.
Ch. 1 - Introduction - Robotic Manipulation
In the previous exercise, you manually set up a simulation by creating a `DiagramBuilder`, adding a `MultibodyPlant` and `SceneGraph`, loading robots, and wiring everything together. In this exercise, you will learn to use `HardwareStation` and model directives specified in `YAML` configuration file
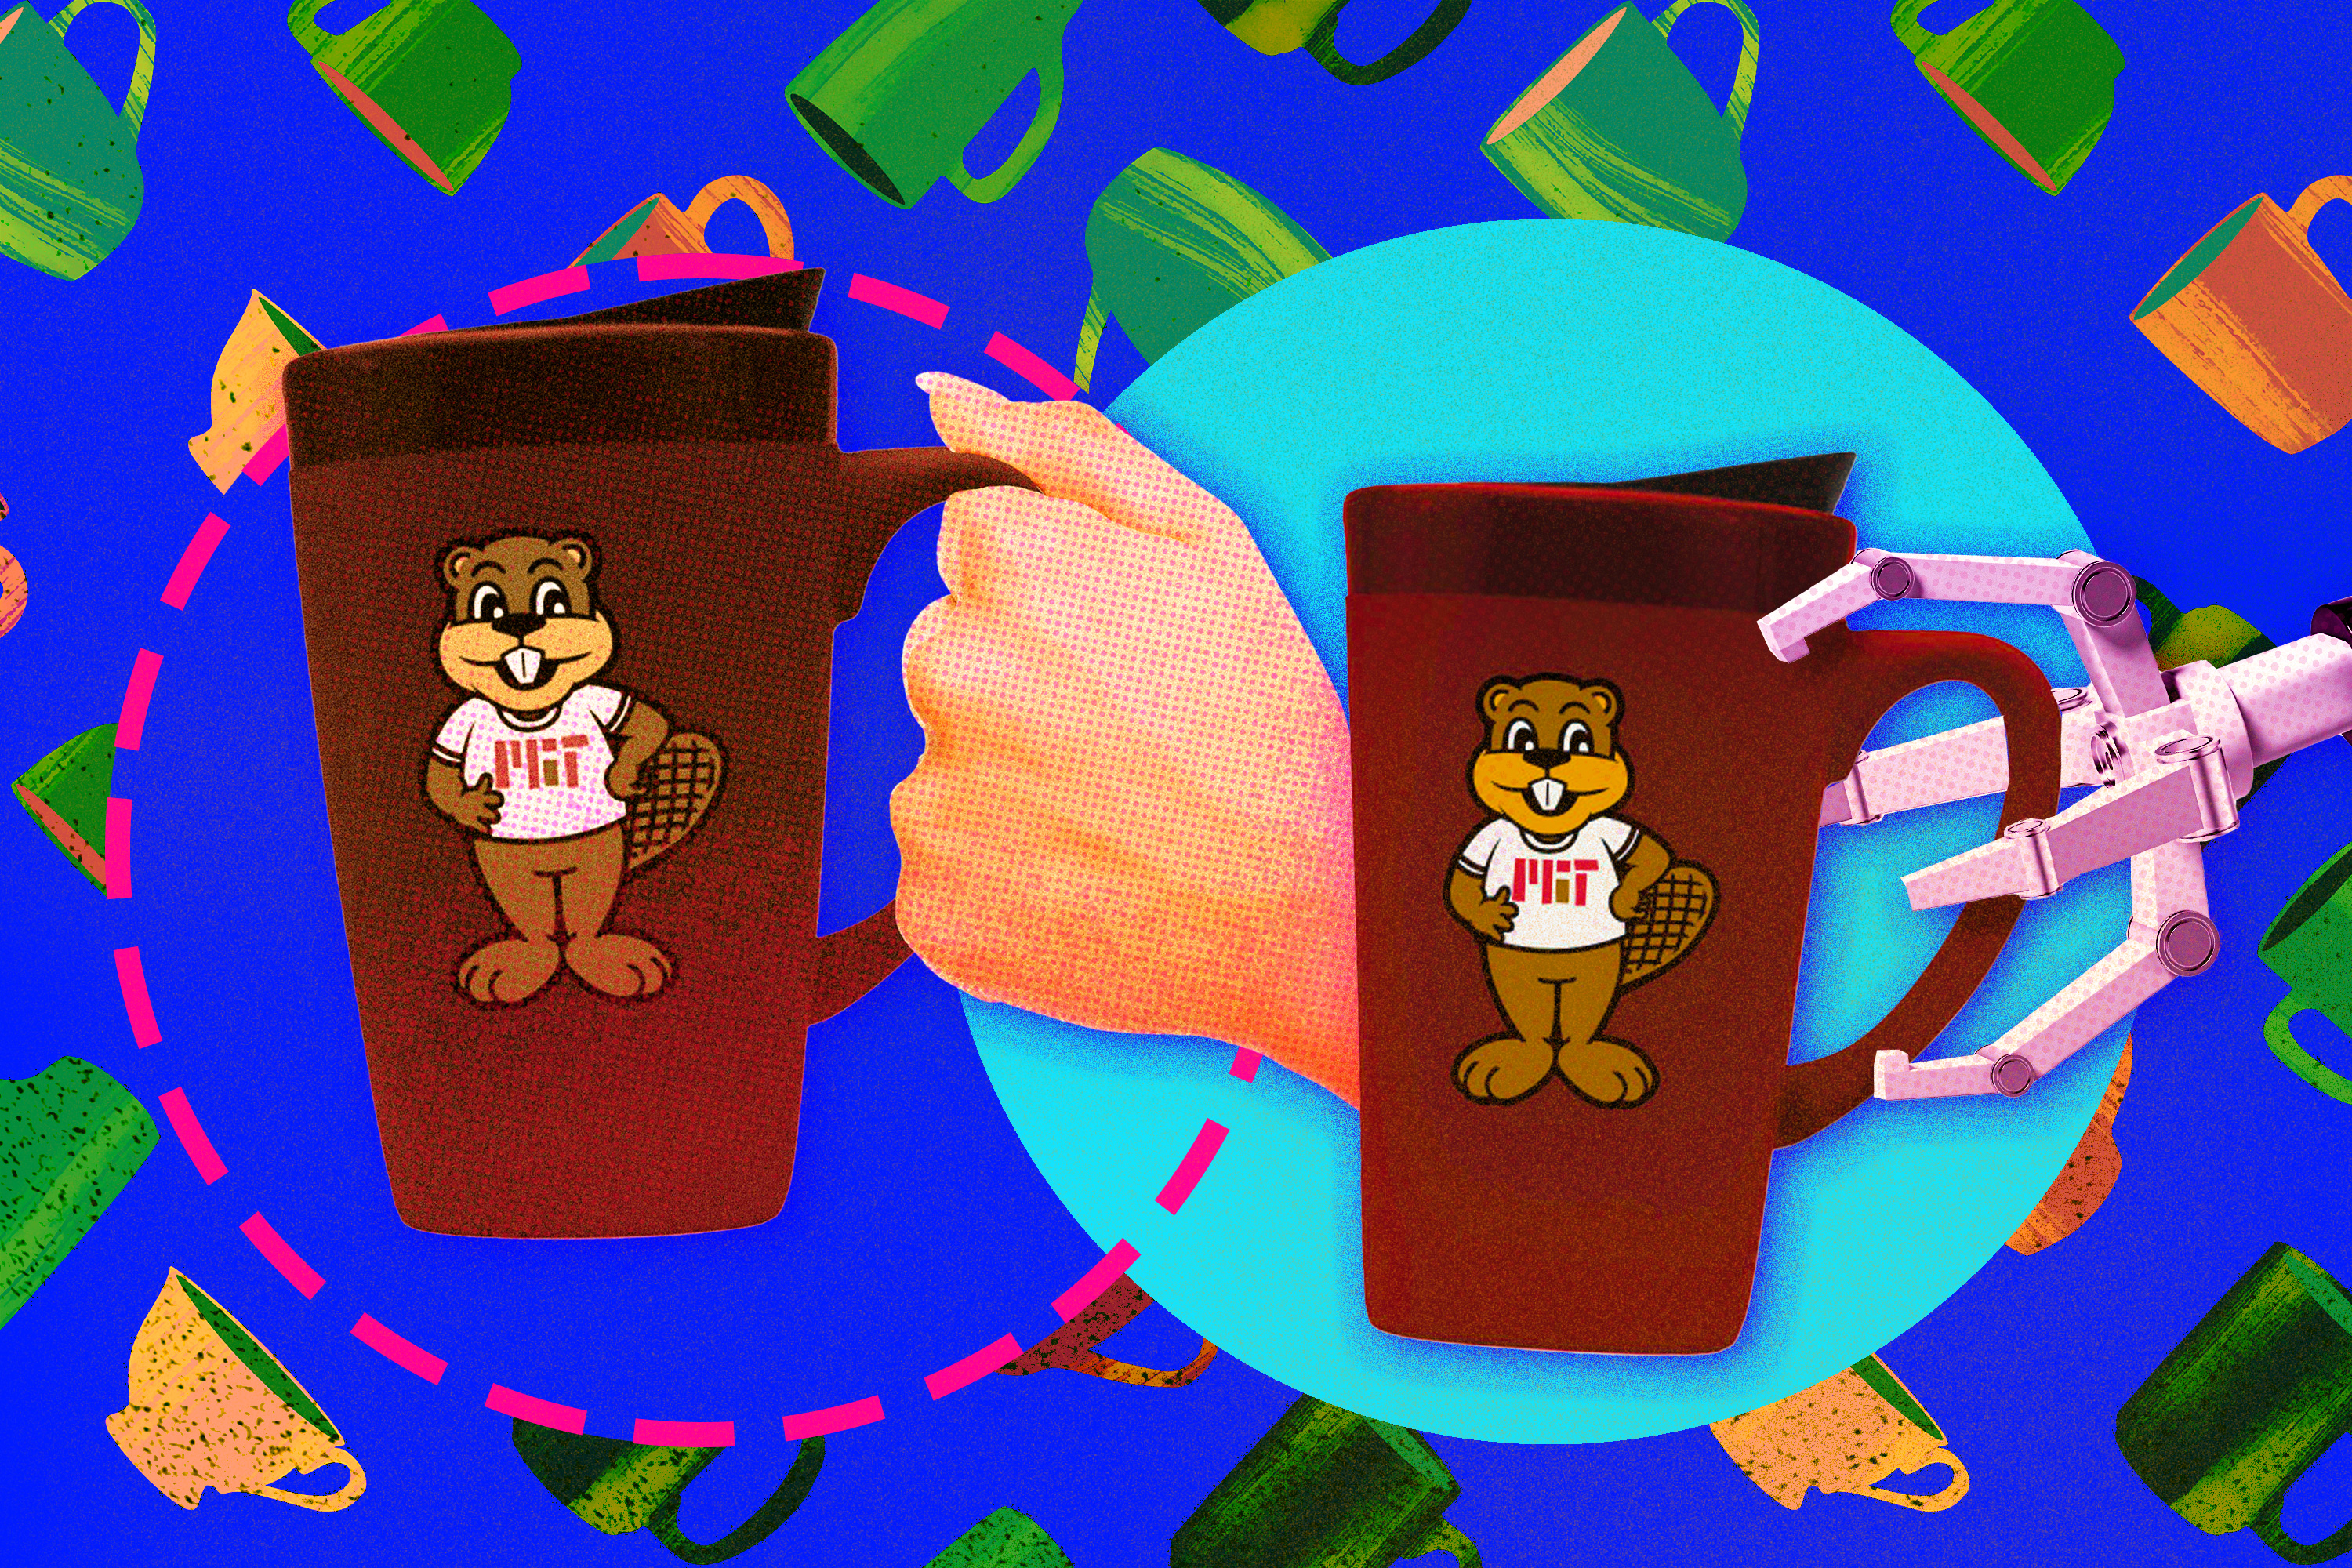
A faster way to teach a robot
A new technique enables a human to efficiently fine-tune a robot that failed to complete a desired task with very little effort on the part of the human. Their system uses algorithms, counterfactual explanations, and feedback from the user to generate synthetic data it uses to quickly fine-tune the
Drake: Gallery
# Gallery If you have an example from your own work that you would like to showcase, please edit `doc/_pages/gallery.md` directly and submit a pull request! `doc/_pages/gallery.md` # Underactuated Robotics Drake is being used to teach Underactuated Robotics at MIT. The course textbook has numero
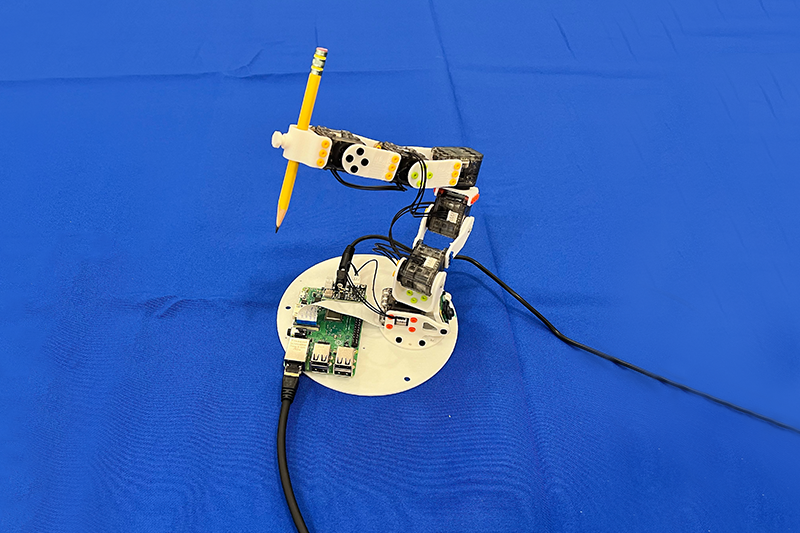
Robot, know thyself: New vision-based system teaches machines to understand their bodies
A vision-based control system called Neural Jacobian Fields enables soft and rigid robots to learn self-supervised motion control using only a monocular camera. The system, developed by MIT CSAIL researchers, combines 3D scene reconstruction with embodied representation and closed-loop control.
Robots that use these skills
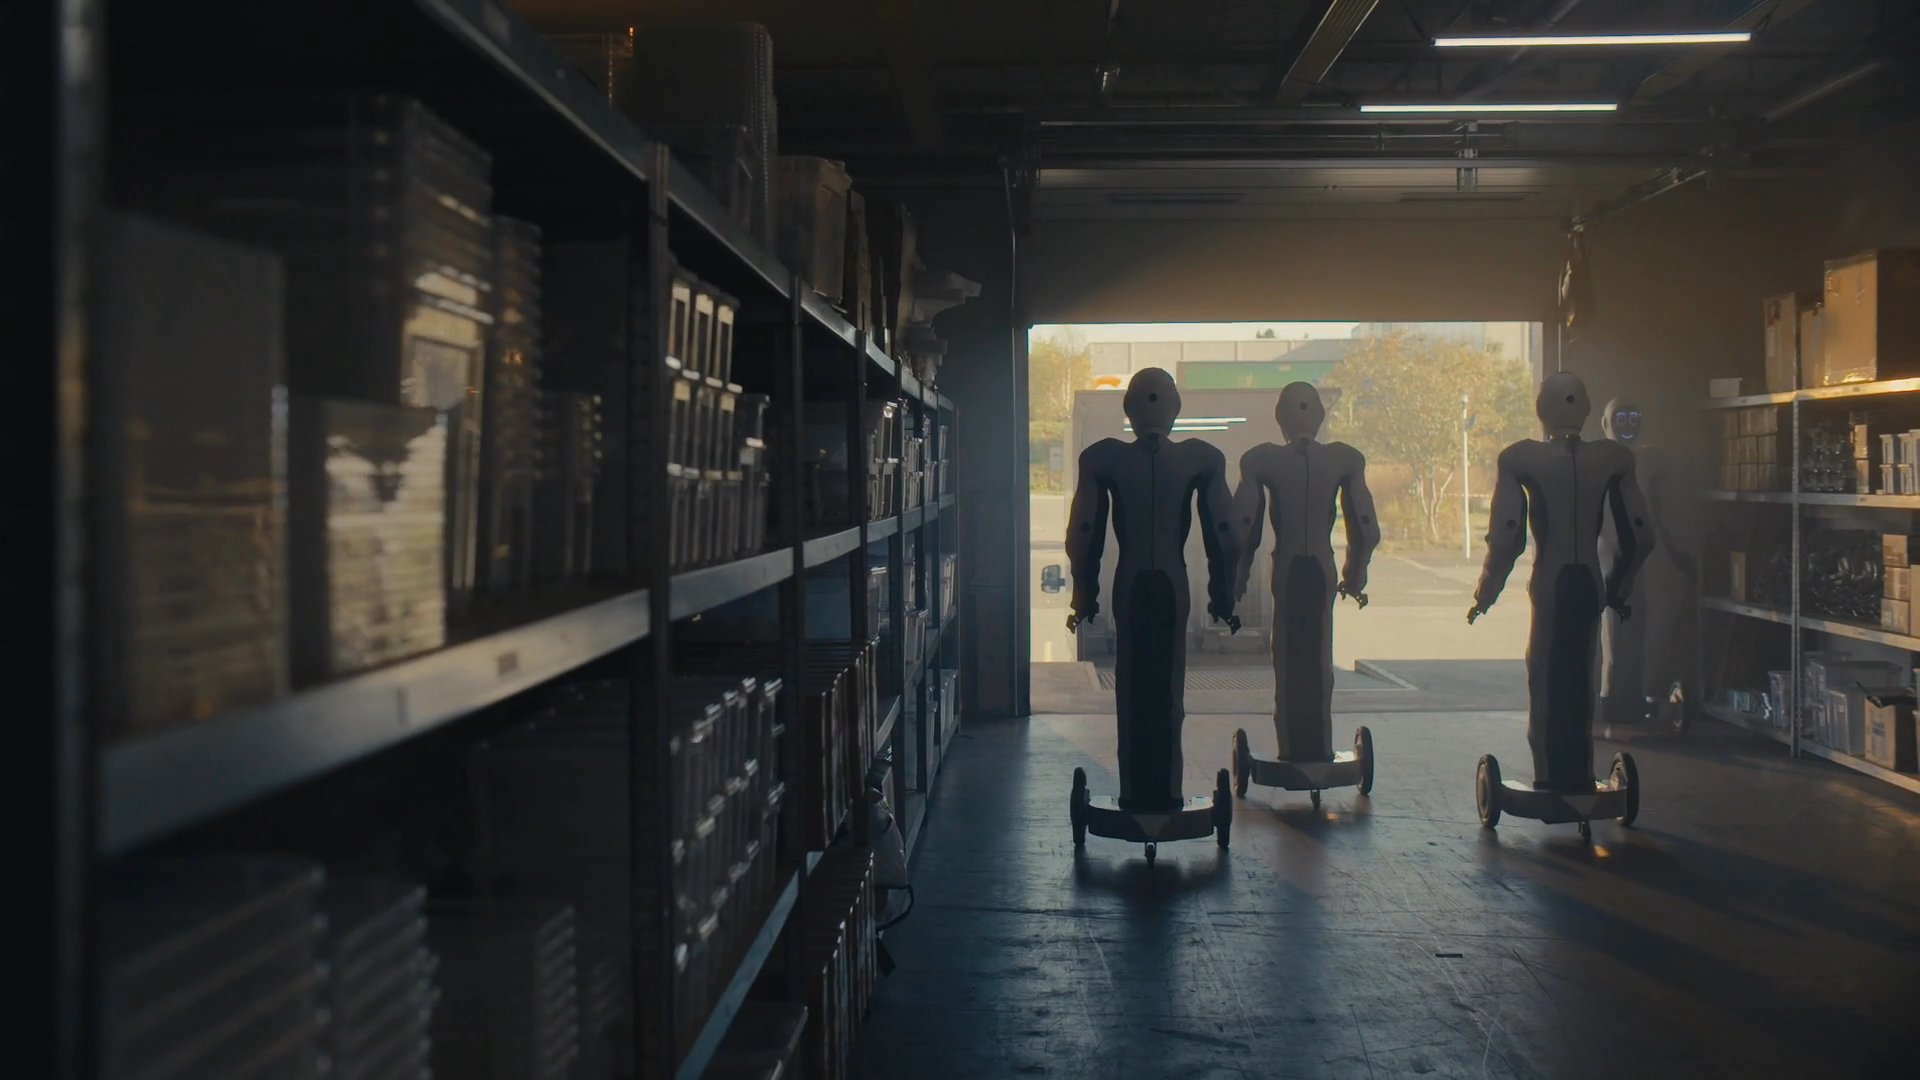
1X EVE
1X Technologies
1X EVE is a wheeled humanoid robot from 1X Technologies aimed at mobile service work in institutional and industrial settings.
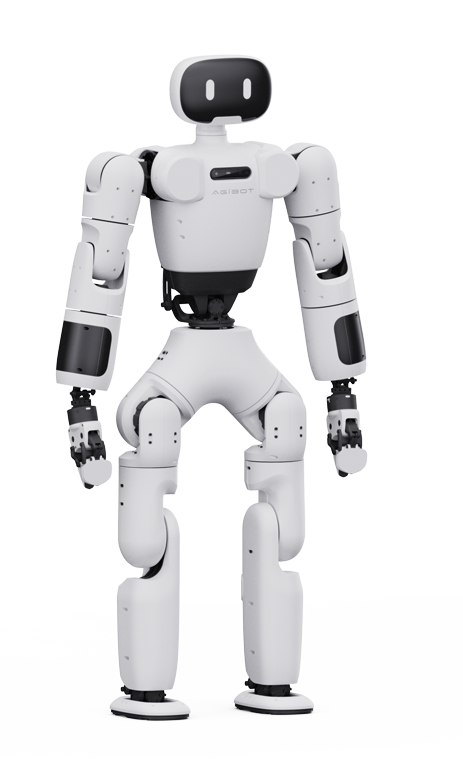
AgiBot X1
AgiBot
AgiBot X1 is a 130 cm, 33 kg open-source humanoid platform with 34 DOF for research and education.

AiNex ROS Education AI Vision Humanoid Robot
Hiwonder
AiNex is a compact ROS-enabled educational humanoid robot from Hiwonder with an HD camera for AI vision experiments.
Refer a learner and get early access to our paid pathways and 1:1 mentorship pilot.
Join referral listNew robots, industry moves, and funding in your weekly robotics briefing.
Unsubscribe anytime.