Humanoid Robotics HUMANOID ROBOTS: A NEW KIND OF TOOL
Just as computer simulations of neural nets have been used to explore and refine models from neuroscience, we can use humanoid robots to investigate and validate models from cognitive science and behavioral science. We have used the following four examples of biological models in our research. Devel

Before you start
- Basic Python familiarity
- Comfort with algebra or calculus basics
- Interest in robotics systems
About this guide
Just as computer simulations of neural nets have been used to explore and refine models from neuroscience, we can use humanoid robots to investigate and validate models from cognitive science and behavioral science. We have used the following four examples of biological models in our research. Development of reaching and grasping. Infants pass through a sequence of stages in learning hand-eye coordination.5 We have implemented a system for reaching to a visual target that follows this biological
Common questions
What will I learn in Humanoid Robotics HUMANOID ROBOTS: A NEW KIND OF TOOL?
Just as computer simulations of neural nets have been used to explore and refine models from neuroscience, we can use humanoid robots to investigate and validate models from cognitive science and behavioral science. We have used the following four examples of biological models in
Is Humanoid Robotics HUMANOID ROBOTS: A NEW KIND OF TOOL free?
HumanoidHub has not verified public pricing for this guide. Open MIT OpenCourseWare for the current access terms before enrolling.
Do I need any prerequisites?
Recommended prep: Basic Python familiarity; Comfort with algebra or calculus basics; Interest in robotics systems.
How long does it take?
1 hours total. Most learners complete this guide in self-directed sessions over a few weeks.
Does it offer a certificate?
This guide does not include a formal certificate. Focus is on the learning material itself.
Related guides
A faster way to teach a robot
A new technique enables a human to efficiently fine-tune a robot that failed to complete a desired task with very little effort on the part of the human. Their system uses algorithms, counterfactual explanations, and feedback from the user to generate synthetic data it uses to quickly fine-tune the
Unit 8. Robotics | Brains, Minds and Machines Summer Course | Brain and Cognitive Sciences
This page summarizes the unit topic and activities, and links to lecture videos, notes and further study resources.
[PDF] Children, Humanoid Robots and Caregivers - MIT CSAIL
Conclusions This paper described a framework for developmental object perception and learning on a humanoid robot, which aims at teaching humanoids as children. We described algorithms to learn about the robot’s self appearance and its surrounding world. The epige-netic principle established the fou
[PDF] Foundations for a Theory of Mind for a Humanoid Robot - Research
• Chapter 8 : Detecting Faces and Head Pose One final primitive perceptual process will be required. The robot will need to find human faces in the visual scene and to extract the orientation of the head as a measurement of where that person is attending. This orientation direction will be used later
[PDF] Humanoid Robots: A New Kind of Tool
In 1993, we began a project aimed at con-structing a humanoid robot for use in explor-ing theories of human intelligence.1,2 In addi-tion to the relevant engineering, computer architecture, and real-time-control issues, we’ve had to address issues particular to inte-grated systems:What types of sens
[PDF] Real-Time Interactive Reinforcement Learning for Robots
Particularly, we believe that the transparency of the learner’s internal process is paramount to the success of the tutorial dialog. However, a fine balance must be struck be-tween engulfing the human teacher with all pertinent infor-mation, and leaving them in the dark. A central goal of the presente
Robots that use these skills

HMND 01 Alpha
Humanoid
HMND 01 Alpha is a humanoid-style robot on a wheeled base referenced in a 2025–2026 third-party comparison of humanoid robots. Public, verifiable specs and commercial details are not disclosed in that source.
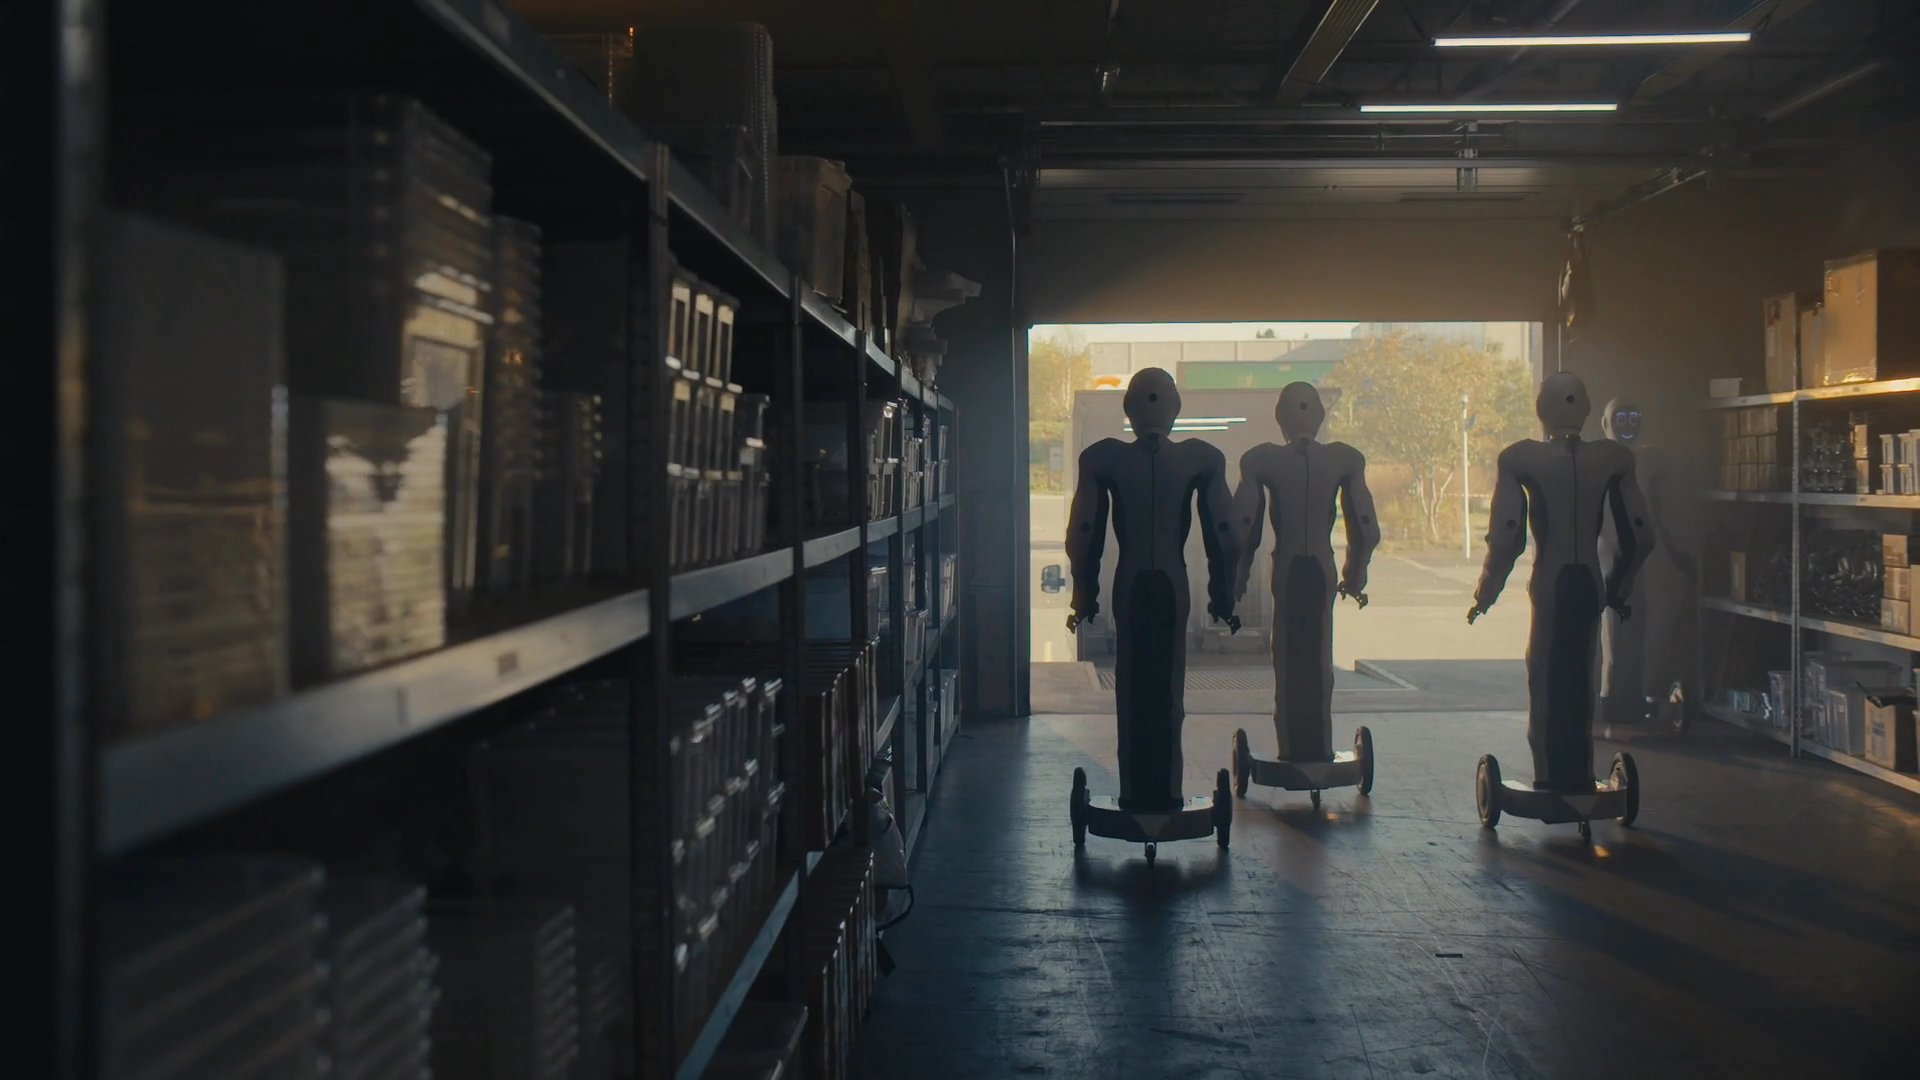
1X EVE
1X Technologies
1X EVE is a wheeled humanoid robot from 1X Technologies aimed at mobile service work in institutional and industrial settings.
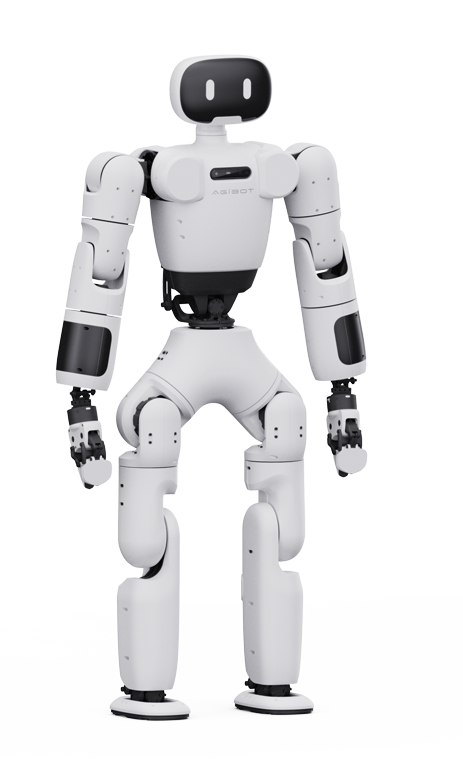
AgiBot X1
AgiBot
AgiBot X1 is a 130 cm, 33 kg open-source humanoid platform with 34 DOF for research and education.
Refer a learner and get early access to our paid pathways and 1:1 mentorship pilot.
Join referral listNew robots, industry moves, and funding in your weekly robotics briefing.
Unsubscribe anytime.