YARP: Yet Another Robot Platform - People | MIT CSAIL
We describe the main problems we faced and the solutions we adopted. In short, the main features of YARP include support for inter-process communication, image processing as well as a class hierarchy to ease code reuse across different hardware platforms. YARP is currently used and tested on Windows

Before you start
- Basic Python familiarity
- Comfort with algebra or calculus basics
- Interest in robotics systems
About this guide
We describe the main problems we faced and the solutions we adopted. In short, the main features of YARP include support for inter-process communication, image processing as well as a class hierarchy to ease code reuse across different hardware platforms. YARP is currently used and tested on Windows, Linux and QNX6 which are common operating systems used in robotics. Keywords: software platform, interprocess communication, humanoid robotics 1. Introduction YARP is written by and for researchers
Common questions
What will I learn in YARP: Yet Another Robot Platform - People | MIT CSAIL?
We describe the main problems we faced and the solutions we adopted. In short, the main features of YARP include support for inter-process communication, image processing as well as a class hierarchy to ease code reuse across different hardware platforms. YARP is currently used a
Is YARP: Yet Another Robot Platform - People | MIT CSAIL free?
HumanoidHub has not verified public pricing for this guide. Open MIT OpenCourseWare for the current access terms before enrolling.
Do I need any prerequisites?
Recommended prep: Basic Python familiarity; Comfort with algebra or calculus basics; Interest in robotics systems.
How long does it take?
1 hours total. Most learners complete this guide in self-directed sessions over a few weeks.
Does it offer a certificate?
This guide does not include a formal certificate. Focus is on the learning material itself.
Related guides
A faster way to teach a robot
A new technique enables a human to efficiently fine-tune a robot that failed to complete a desired task with very little effort on the part of the human. Their system uses algorithms, counterfactual explanations, and feedback from the user to generate synthetic data it uses to quickly fine-tune the
Unit 8. Robotics | Brains, Minds and Machines Summer Course | Brain and Cognitive Sciences
This page summarizes the unit topic and activities, and links to lecture videos, notes and further study resources.
[PDF] Children, Humanoid Robots and Caregivers - MIT CSAIL
Conclusions This paper described a framework for developmental object perception and learning on a humanoid robot, which aims at teaching humanoids as children. We described algorithms to learn about the robot’s self appearance and its surrounding world. The epige-netic principle established the fou
[PDF] Foundations for a Theory of Mind for a Humanoid Robot - Research
• Chapter 8 : Detecting Faces and Head Pose One final primitive perceptual process will be required. The robot will need to find human faces in the visual scene and to extract the orientation of the head as a measurement of where that person is attending. This orientation direction will be used later
[PDF] Humanoid Robots: A New Kind of Tool
In 1993, we began a project aimed at con-structing a humanoid robot for use in explor-ing theories of human intelligence.1,2 In addi-tion to the relevant engineering, computer architecture, and real-time-control issues, we’ve had to address issues particular to inte-grated systems:What types of sens
[PDF] Real-Time Interactive Reinforcement Learning for Robots
Particularly, we believe that the transparency of the learner’s internal process is paramount to the success of the tutorial dialog. However, a fine balance must be struck be-tween engulfing the human teacher with all pertinent infor-mation, and leaving them in the dark. A central goal of the presente
Robots that use these skills
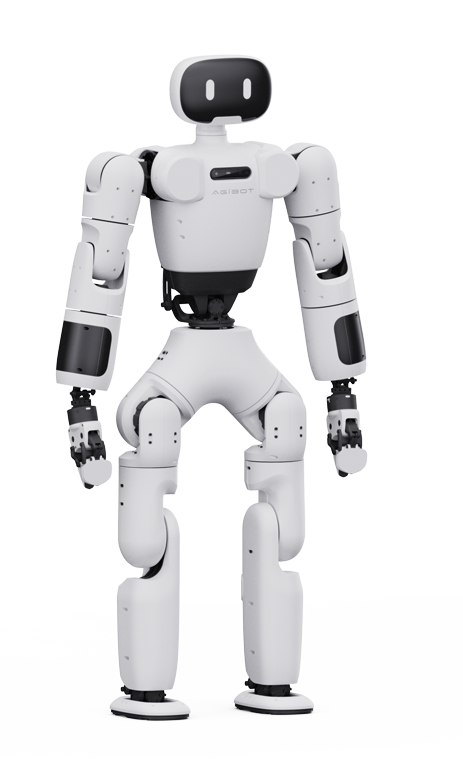
AgiBot X1
AgiBot
AgiBot X1 is a 130 cm, 33 kg open-source humanoid platform with 34 DOF for research and education.
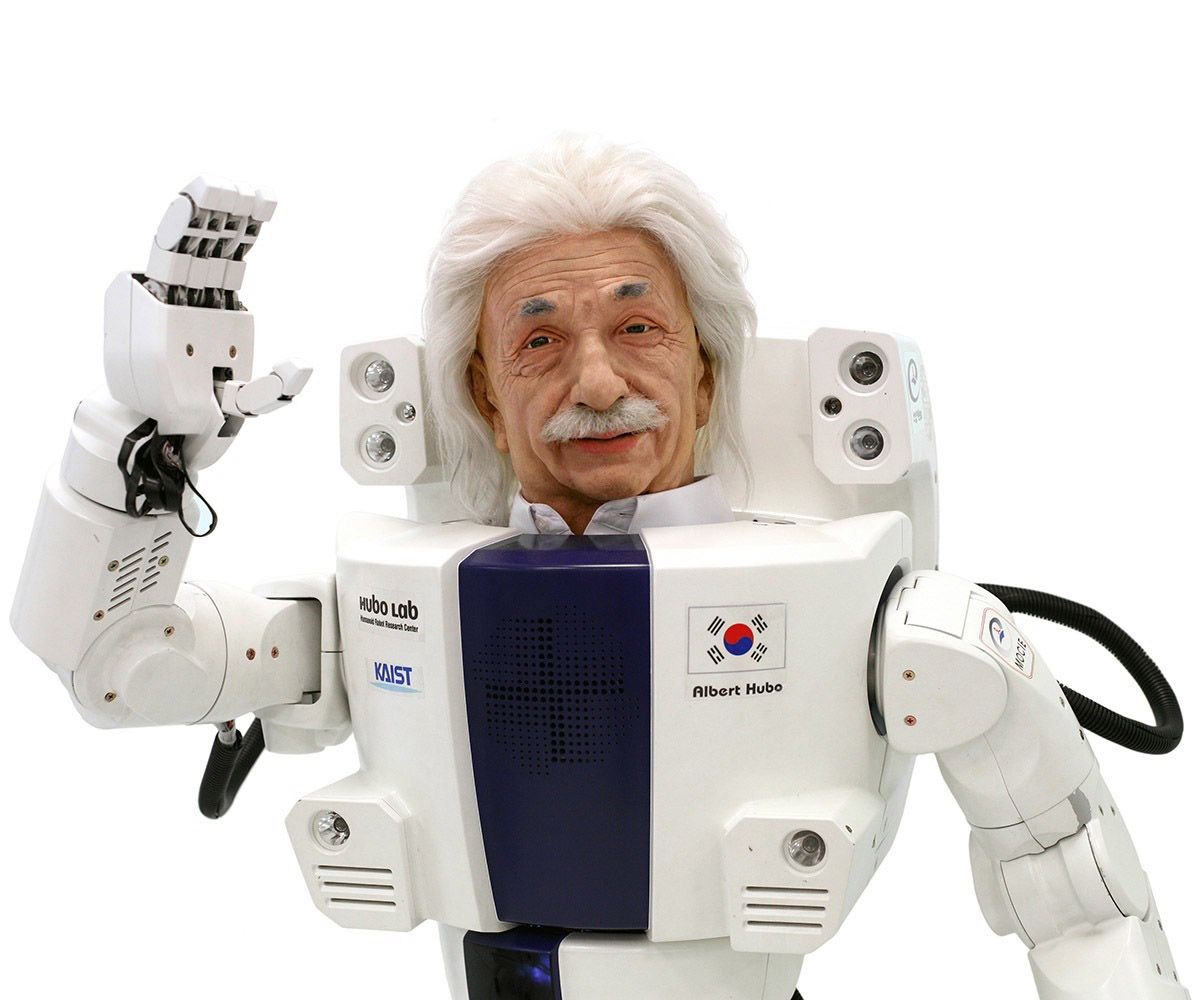
Albert Hubo
HUBO
Albert HUBO is a KAIST HUBO-platform humanoid with an expressive Einstein-like animatronic head for HRI demos and research.
CL-1 Humanoid Robot
LimX Dynamics
CL-1 is a bipedal humanoid robot platform by LimX Dynamics intended for R&D and real-world automation trials.
Refer a learner and get early access to our paid pathways and 1:1 mentorship pilot.
Join referral listNew robots, industry moves, and funding in your weekly robotics briefing.
Unsubscribe anytime.